Sim2real pipeline
Isaac Lab training environments, reward shaping, action and observation scaling, ONNX export, and on-robot inference on NVIDIA Jetson.
IP package for companies
License our sim2real and real2sim pipeline and the GOAT RACER reference design for internal use. Your team starts from a working physical AI stack, not a blank repo.
Talk to us about a licenseWhy now
Modern robots learn their behavior in simulation. Thousands of copies of the robot train in parallel on one GPU. The policy is checked on a digital twin, then one small file goes over the air to one robot. It took us almost 18 months to reach our first real sim-to-real transfer. We already built the loop, and it runs on real robots today.
"Our goal always was to give someone the tools to go make a winning policy, not just give them a winning policy."
What is in the package
Isaac Lab training environments, reward shaping, action and observation scaling, ONNX export, and on-robot inference on NVIDIA Jetson.
Fit motor curves on the bench, build the digital twin in Isaac Sim with OpenUSD, then feed real runs back in to refit the twin and close the gaps.
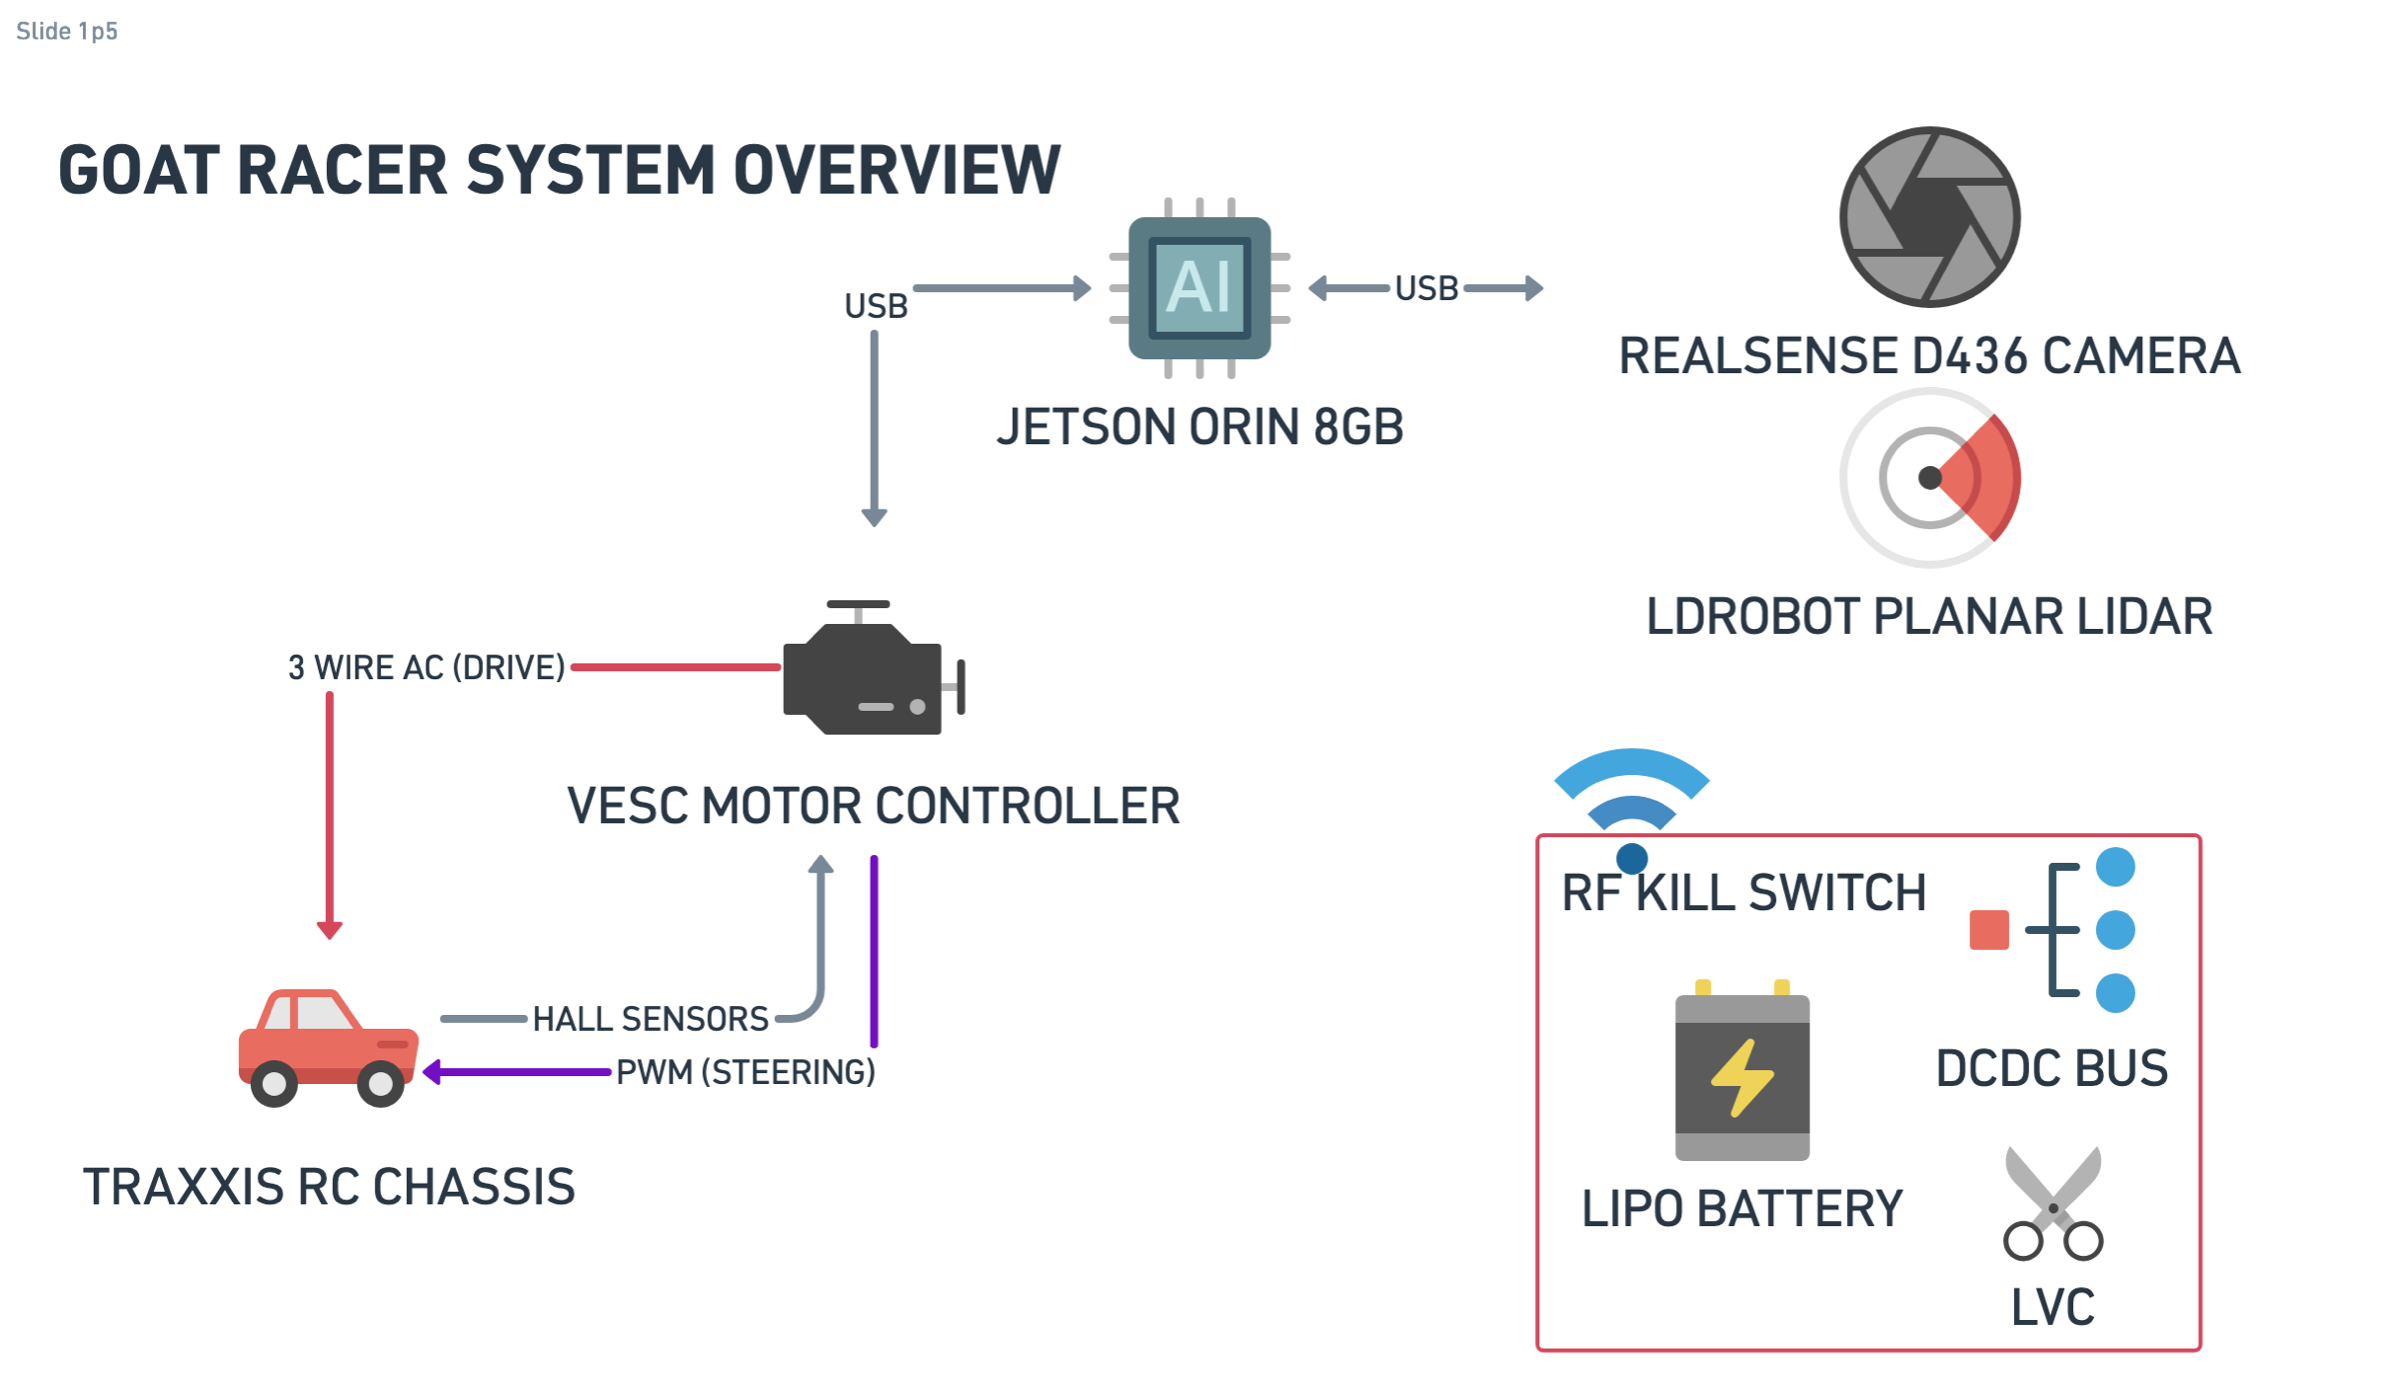
The GOAT RACER PRO hardware: parts list, CAD, Jetson Orin Nano compute, depth camera, lidar, and motor control.
A reproducible Avocado OS base with over-the-air updates through Peridio. Policy updates of about 400 KB, sent to one robot at a time.
An on-site workshop and engineering support, so your engineers run the loop on their own.
The license
Proven in the field
"When I ship an update, the rest of the robot stays completely functional. Only the policy changes."
With Peridio, provisioning a car went from about 3 hours to 10 minutes, and cars stay up for days across policy updates. Watch the video
Next step
Tell us about your robot and your team. We will scope a license and a plan to get you running.