News Build log
Shipping robots like software
Three cars on Docker and SDK Manager did not scale. How Avocado OS and Peridio let us update one car's policy in seconds.
One car is a project. Three cars are a fleet, and a fleet changes everything.
What broke
With one car on JetPack, things were fine. At two, we had a shell script and a large Docker container, and we spent hours trimming container layers. At three, provisioning took about three hours per car through NVIDIA SDK Manager. Versions drifted. Updates landed unevenly. In workshops, the question was always which car had the best policy on it.
"On a robot, you don't need this thing updating."
What we do now
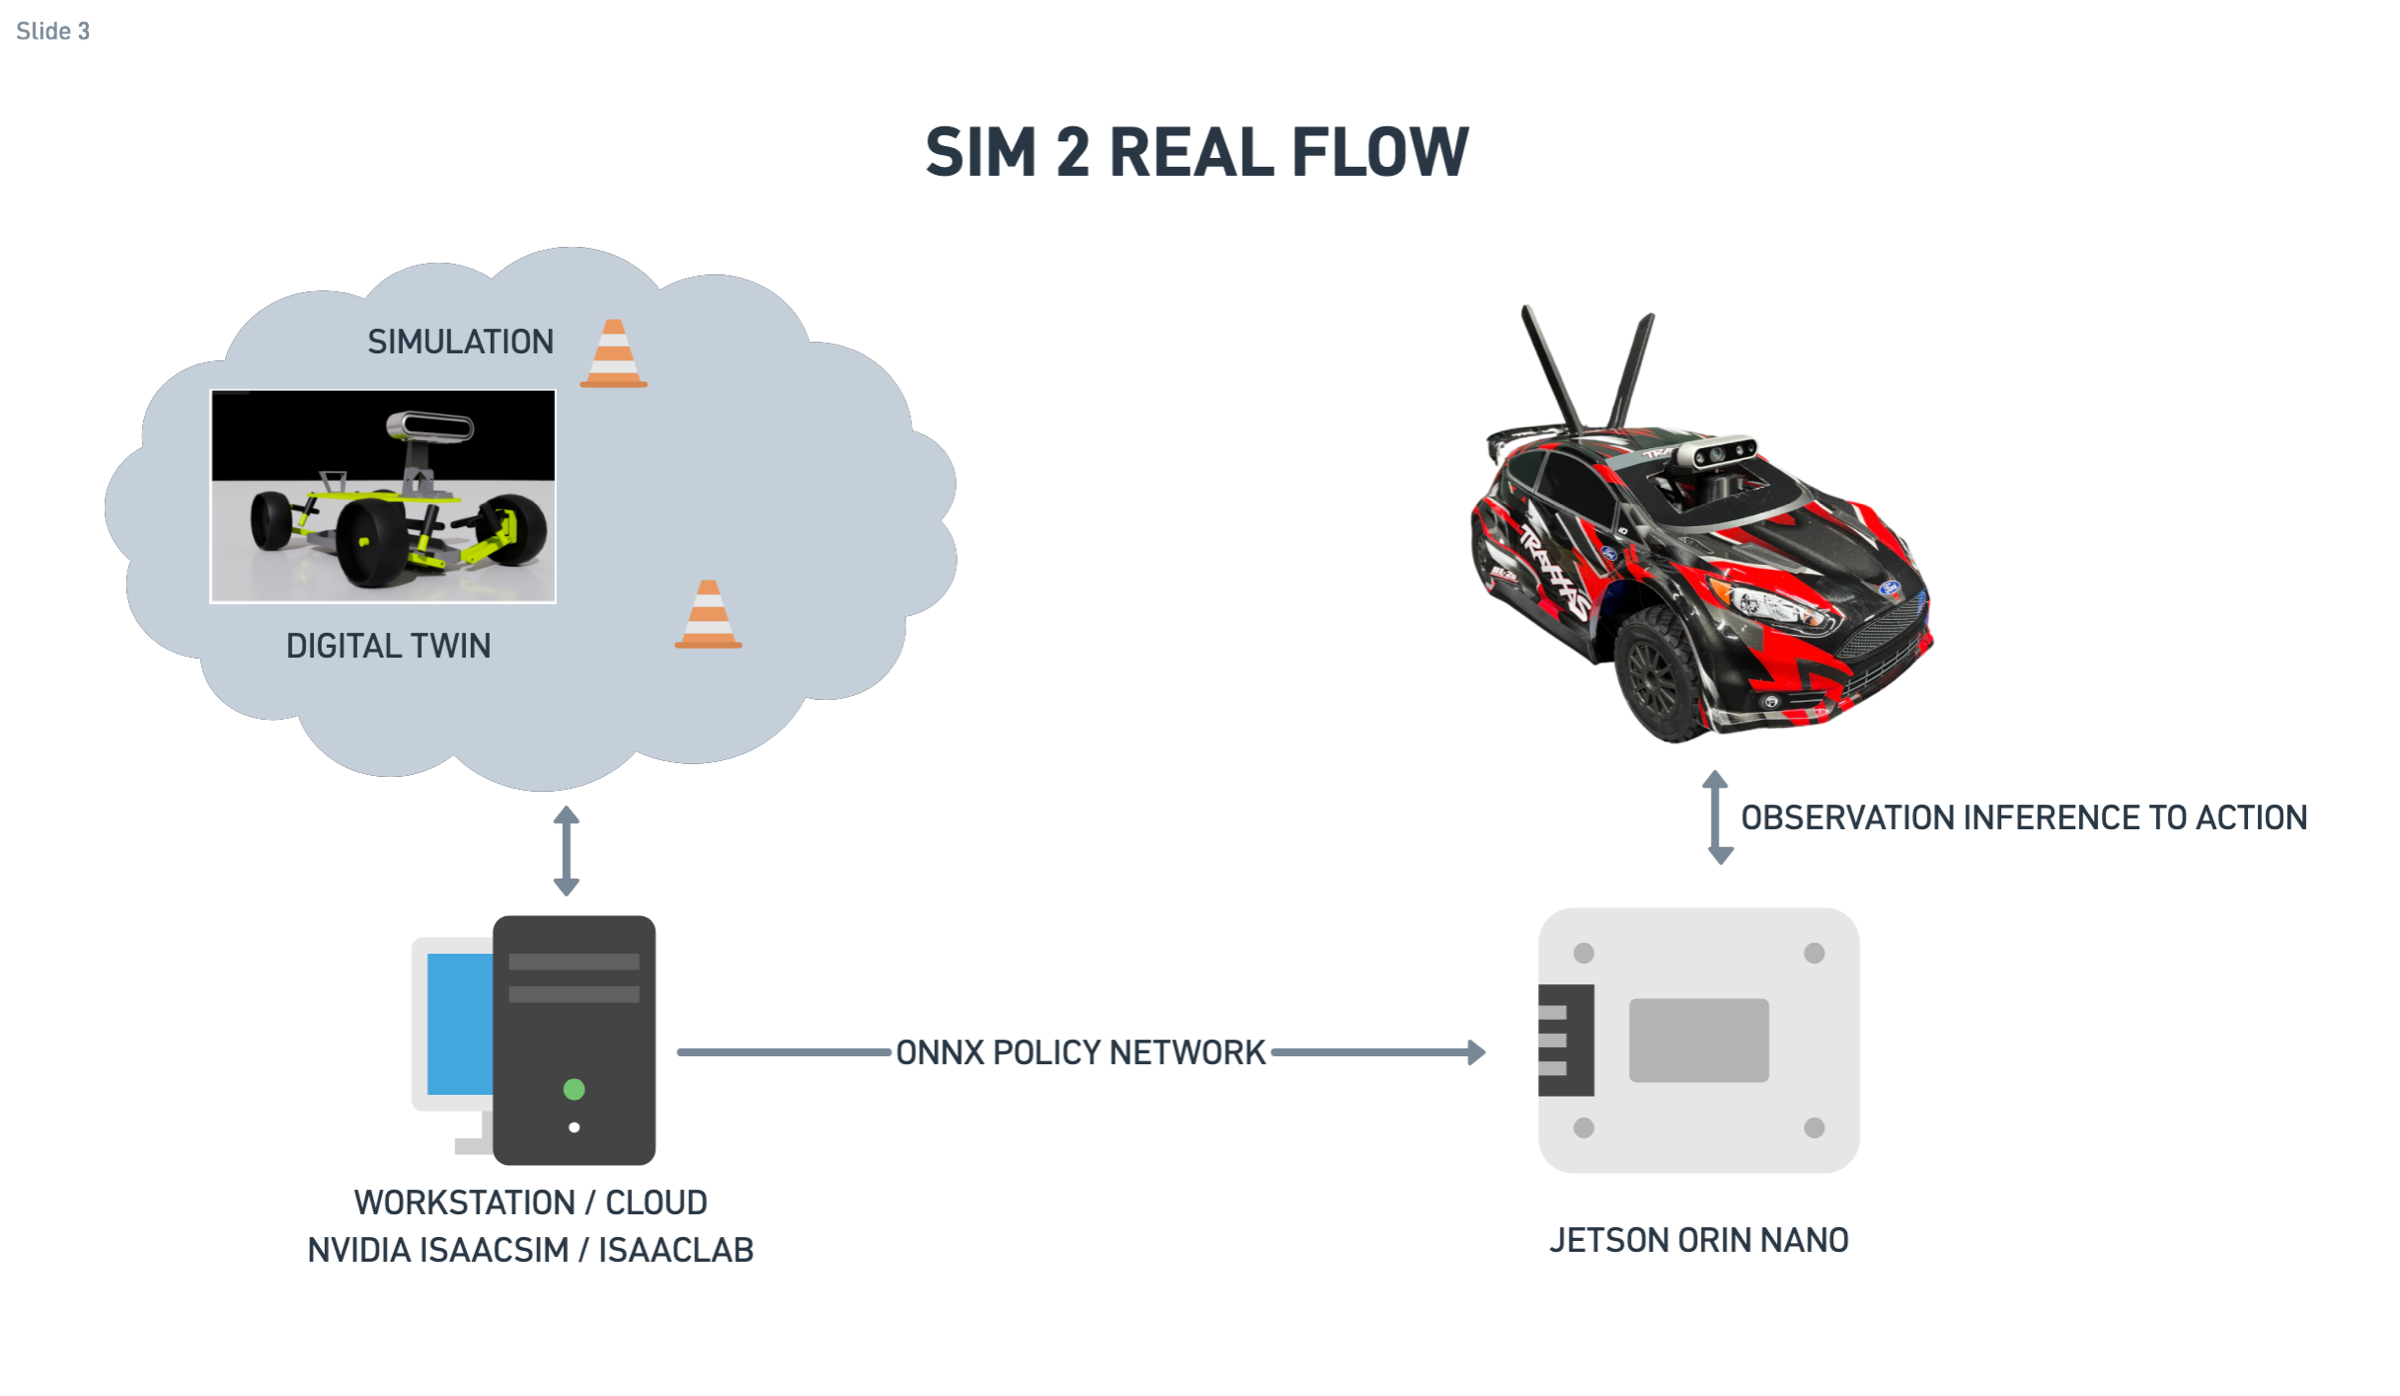
Every GOAT RACER ships on Avocado OS from Peridio: an identical, reproducible base built on Yocto, with A/B boot slots for safe updates. The OS stays fixed. Only the policy changes.
- Provisioning a car: about 3 hours down to 10 minutes.
- A policy update: one ONNX file of about 400 KB, sent over the air to one car.
- Uptime: days without a reboot across policy updates.
"When I ship an update, the rest of the robot stays completely functional. Only the policy changes."
Peridio wrote up the full story: Turnkey sim-to-real robotics on NVIDIA Jetson.