News
From the track and the lab
Research notes, build logs, and news from the team building GOAT RACER.
Featured
GOAT RACER ONE showcase
The digital twin, reinforcement learning, and the real car, in one video.
More on our YouTube channel
Peridio: turnkey sim-to-real on NVIDIA Jetson
Peridio's case study and video on how every GOAT RACER ships on Avocado OS.
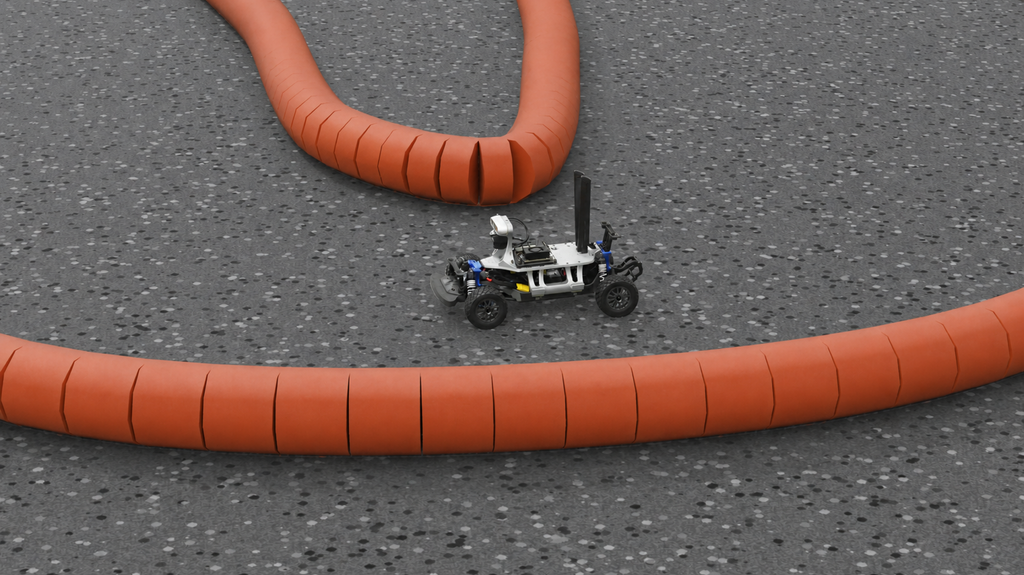
Sim to real: closing the gaps
In progress: where the digital twin and the real car disagree, and how we close each gap.
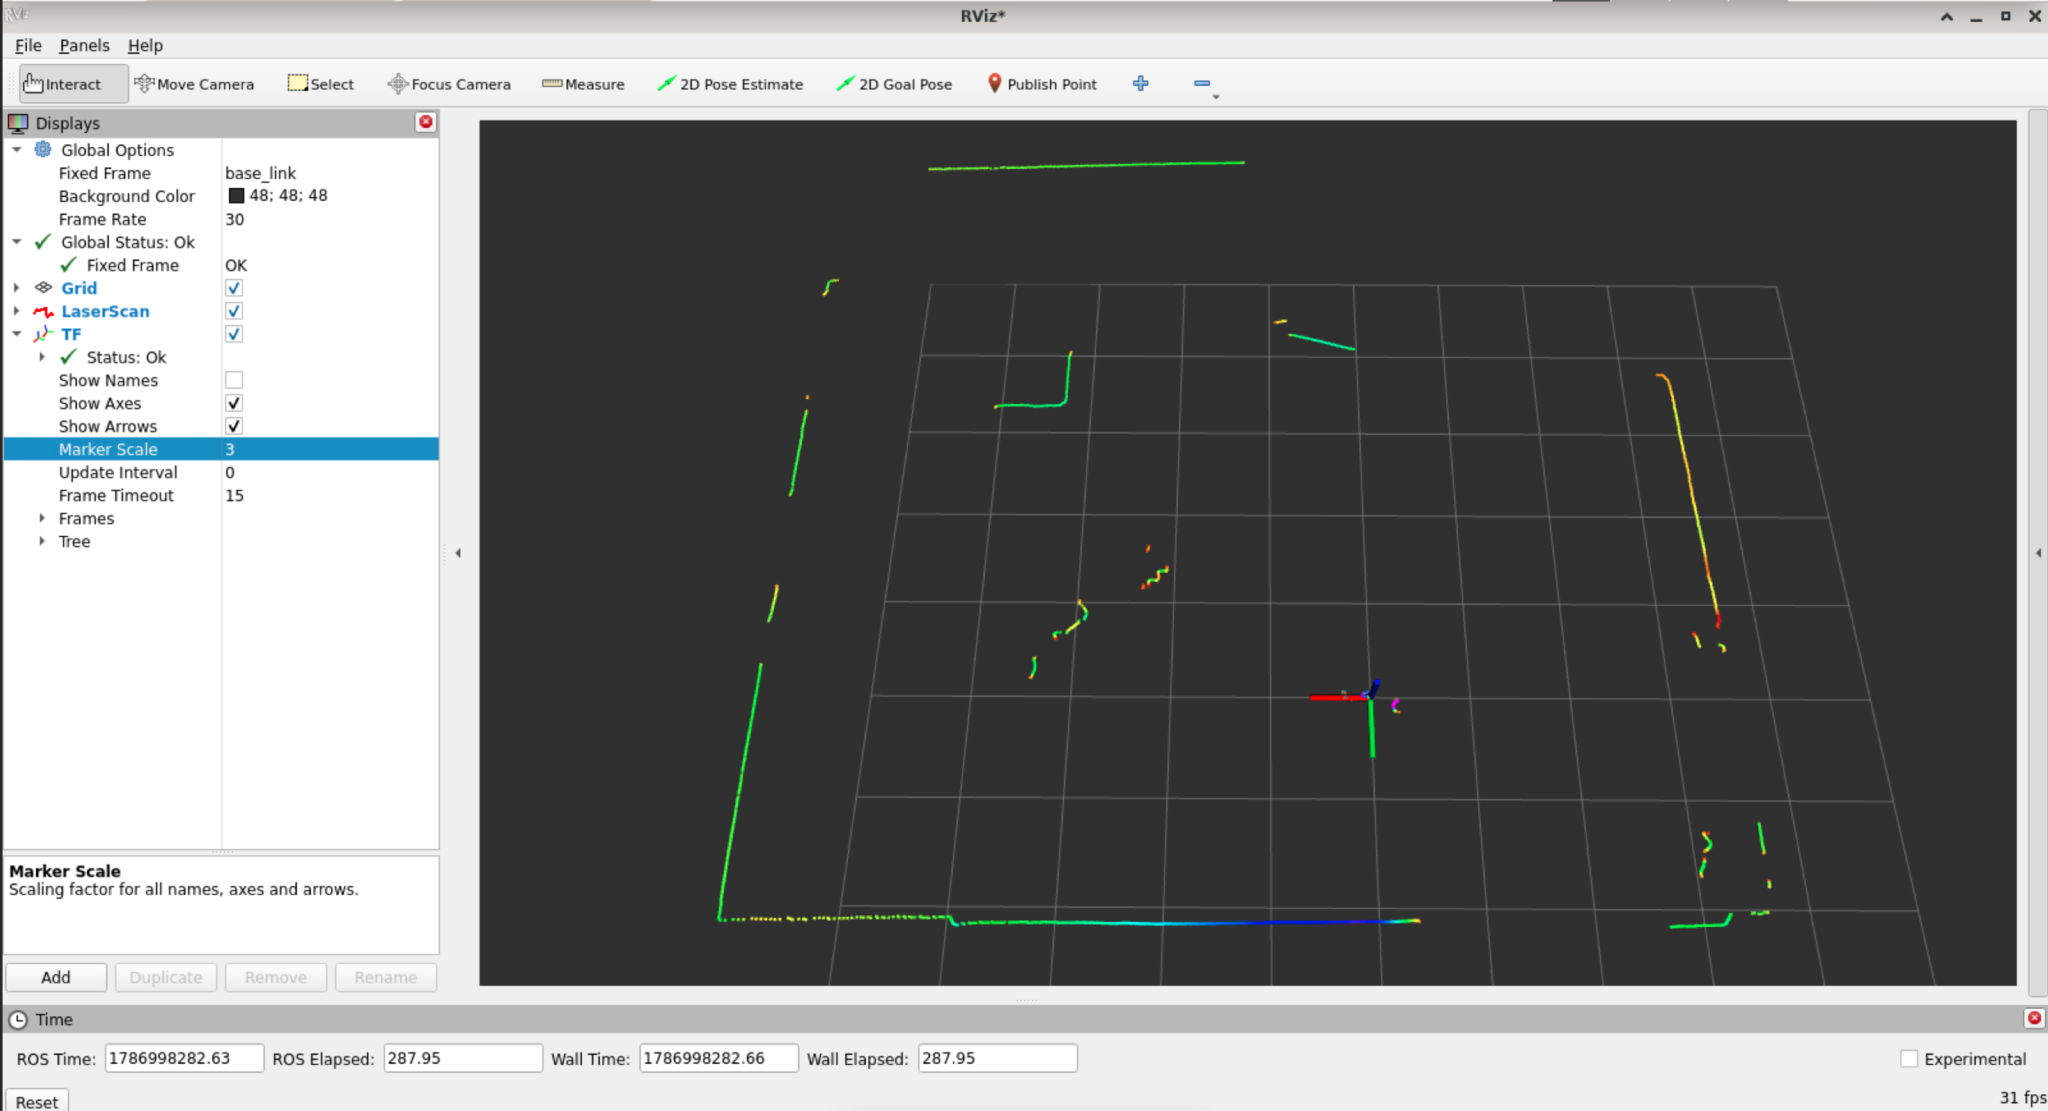
Native ROS 2 Humble on Avocado OS
A ROS 2 Humble extension for Avocado OS, running on GOAT RACER's Jetson Orin Nano.
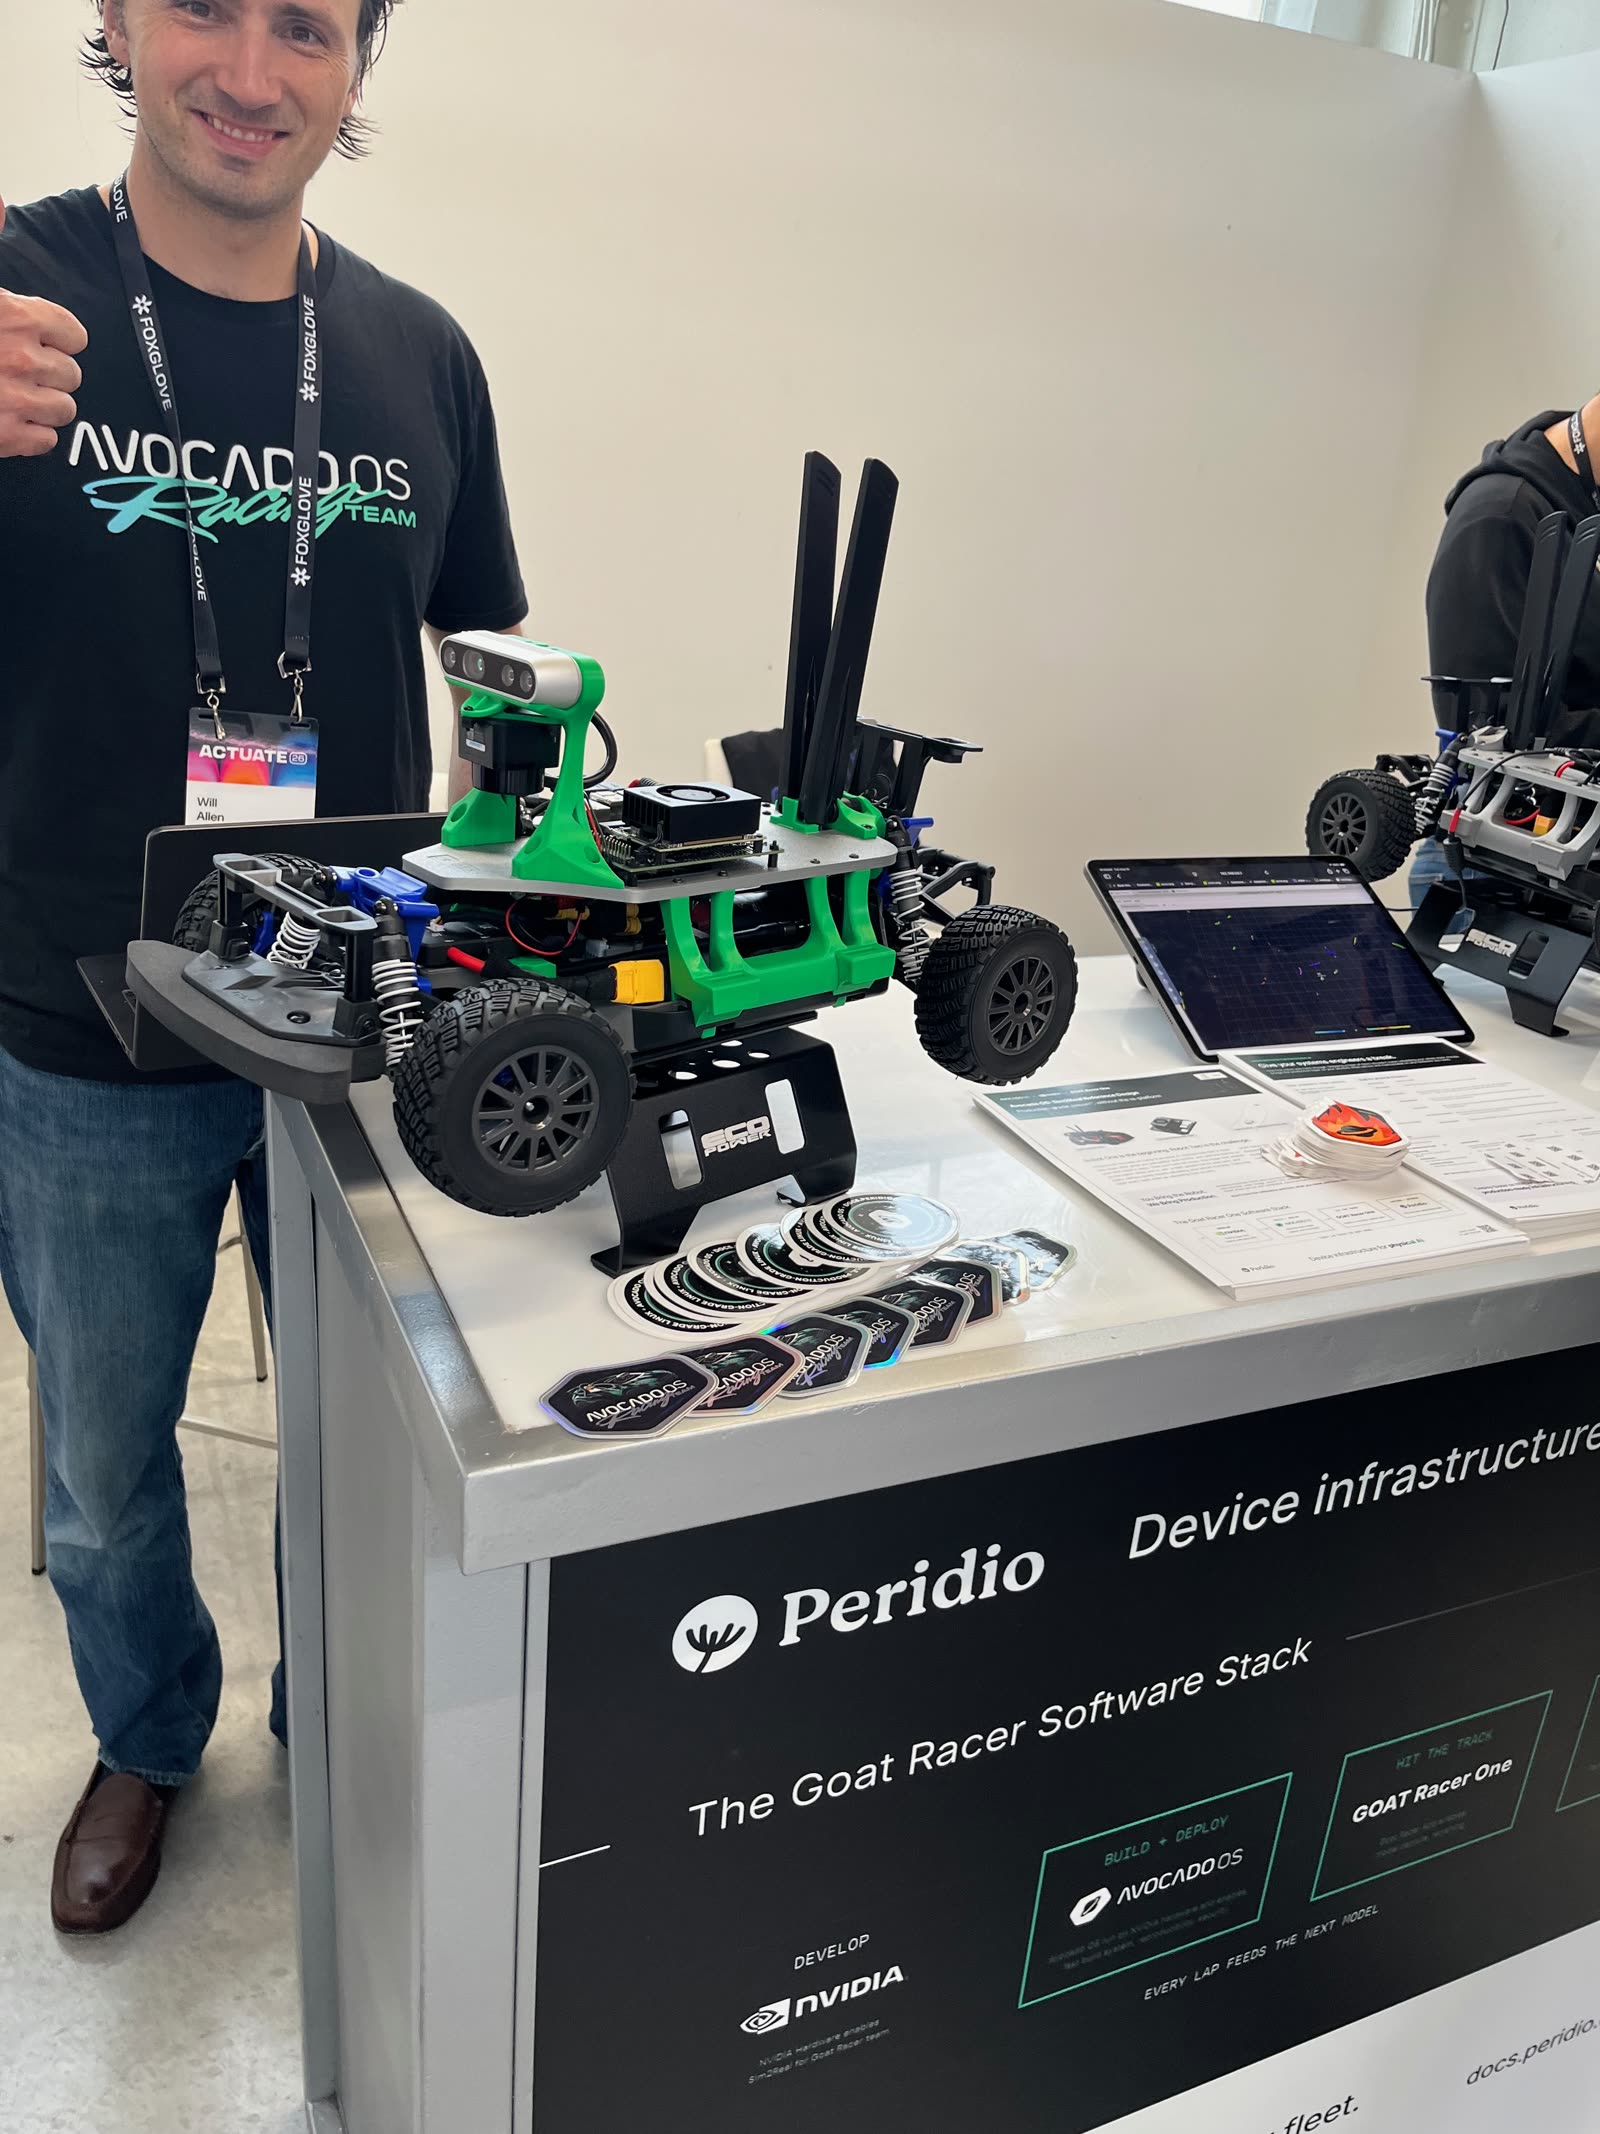
GOAT RACER at Actuate 2026
August 2026: GOAT RACER on the Peridio booth at Actuate.
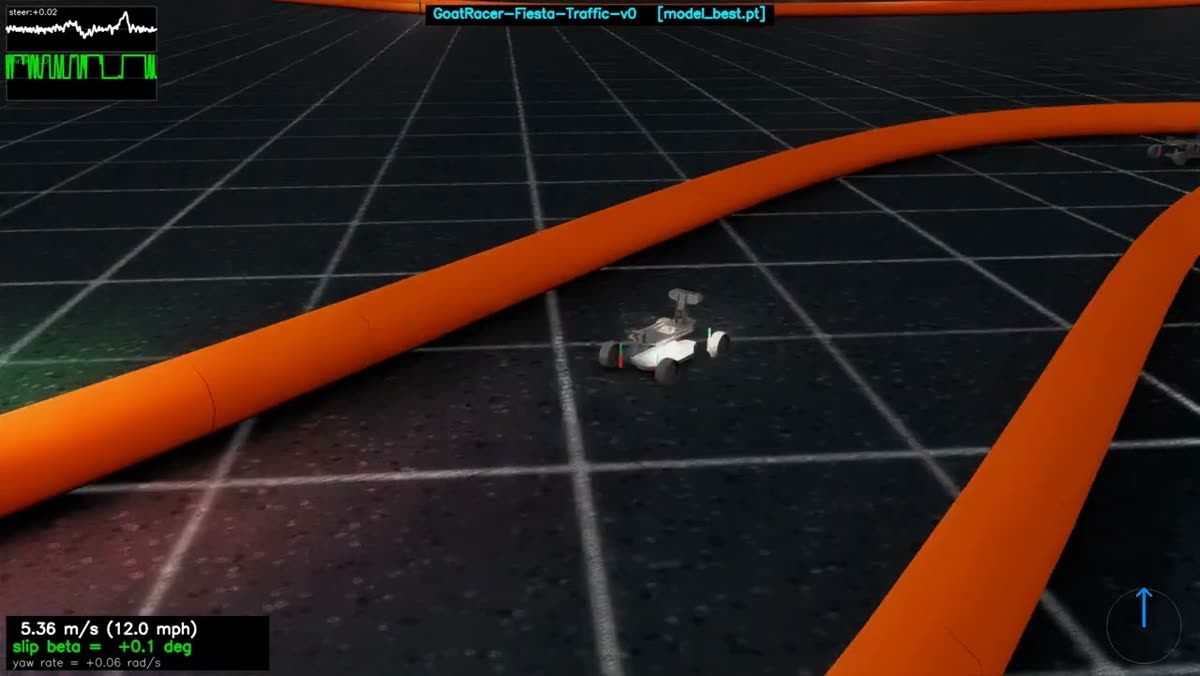
Training on a generated Laguna Seca
August 2026: our track generator builds Laguna Seca for the simulated car, with a live speed and slip readout.
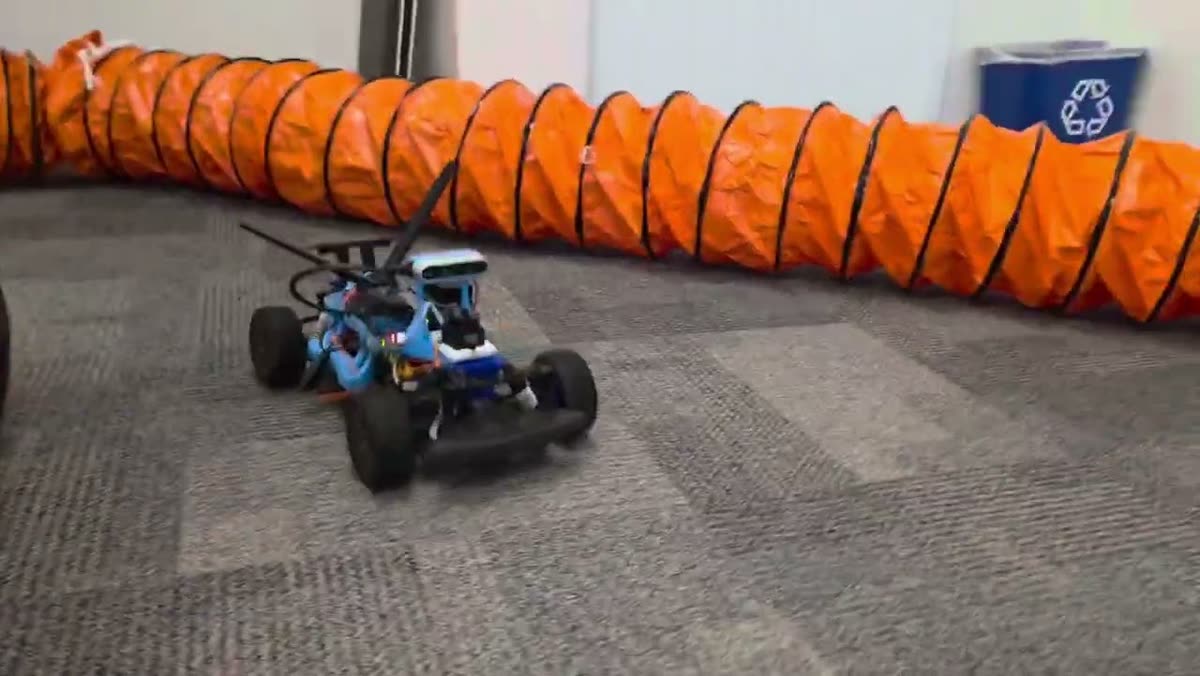
Sim to real on GOAT RACER 2
June 2026: a policy trained in simulation drives GR2 through the hose track.
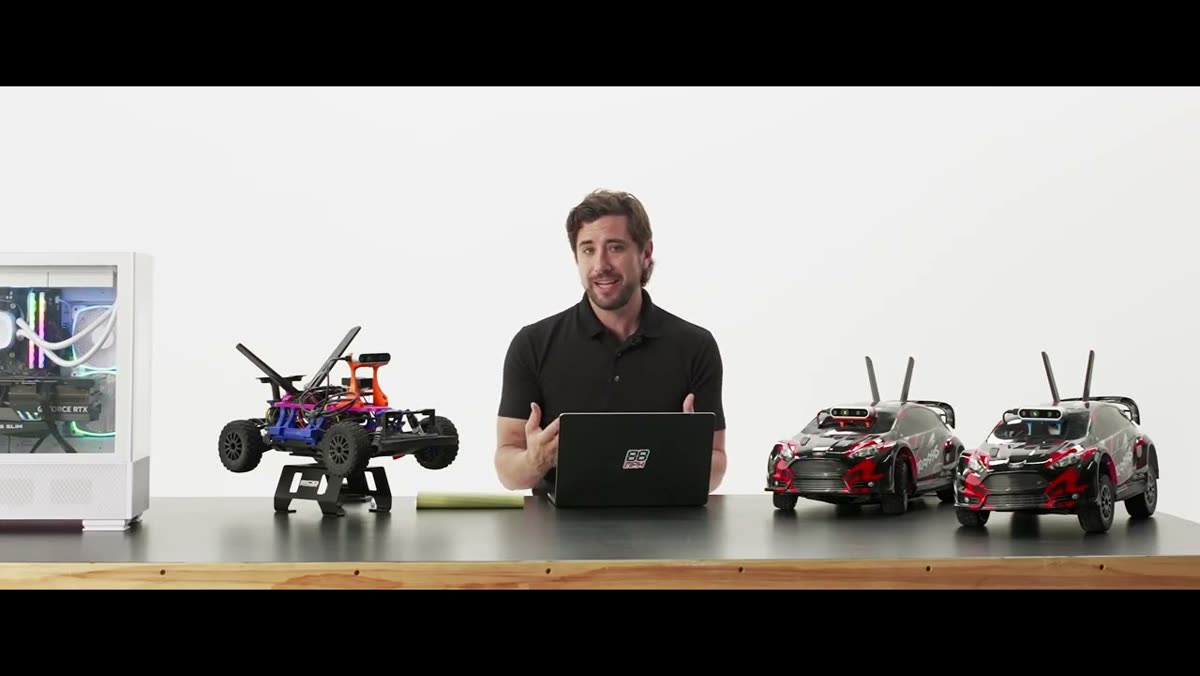
GOAT RACER ONE showcase
The digital twin, reinforcement learning, and the real car, in one video.
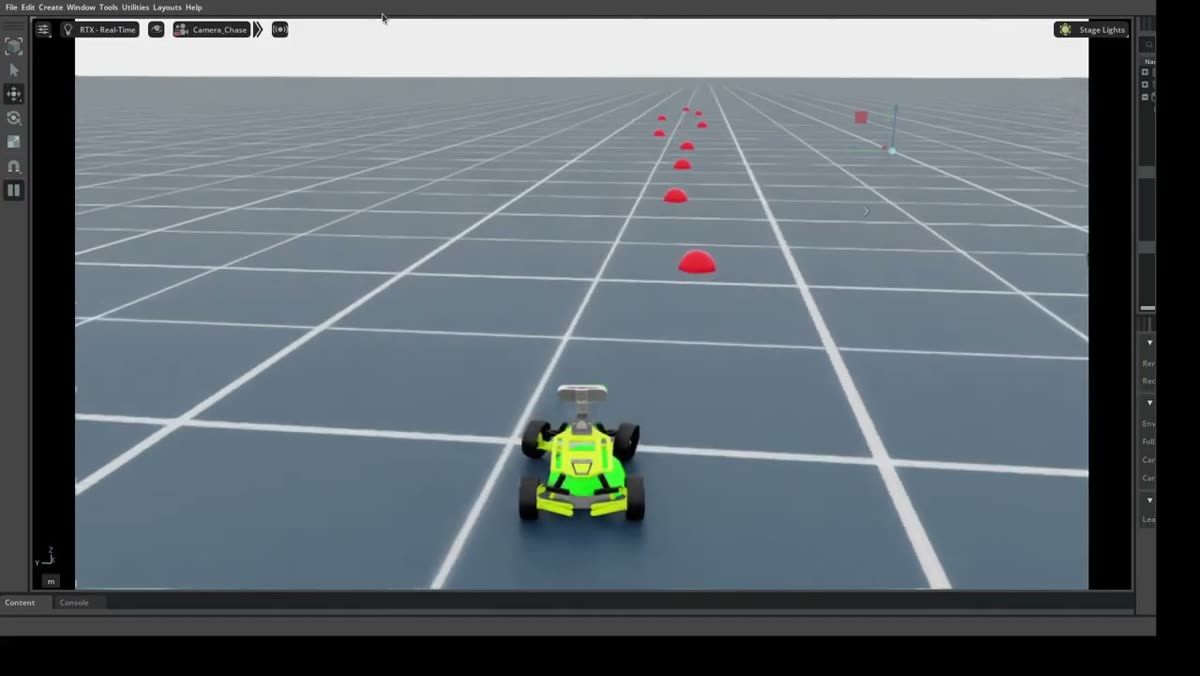
When a good policy drives badly
December 2025: a policy that trained well in simulation oscillates on the real car.
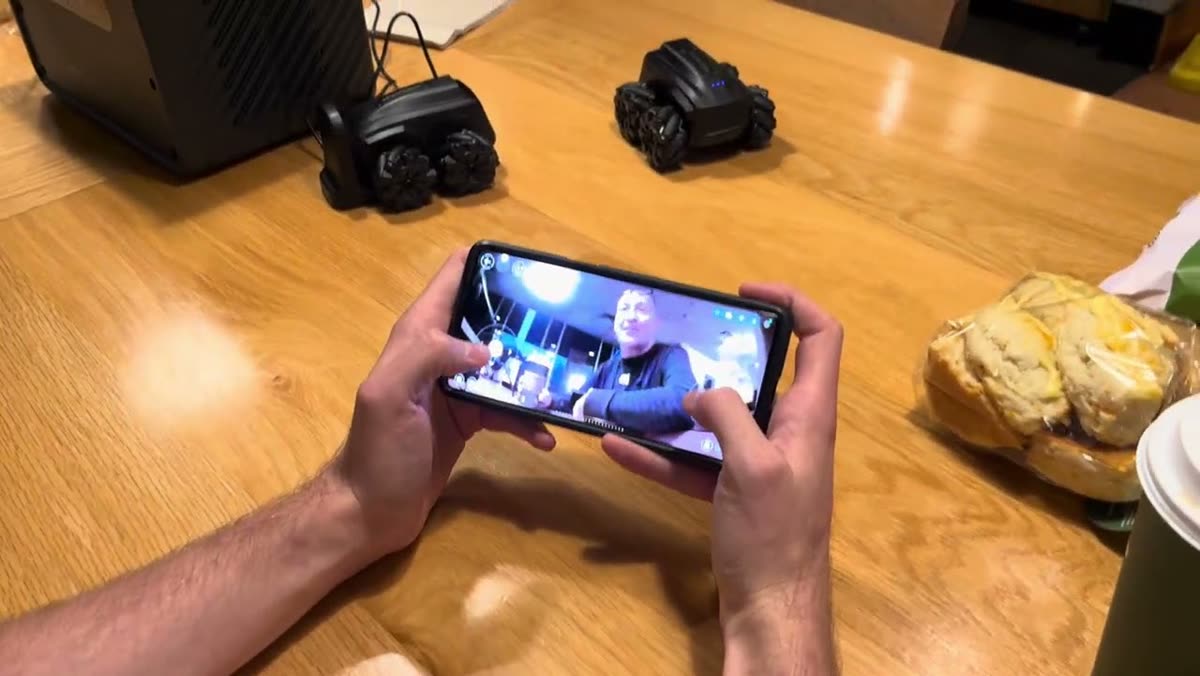
A Moorebot Scout at the GOAT meetup
October 2025: a community member brings a Moorebot Scout to the GOAT meetup.
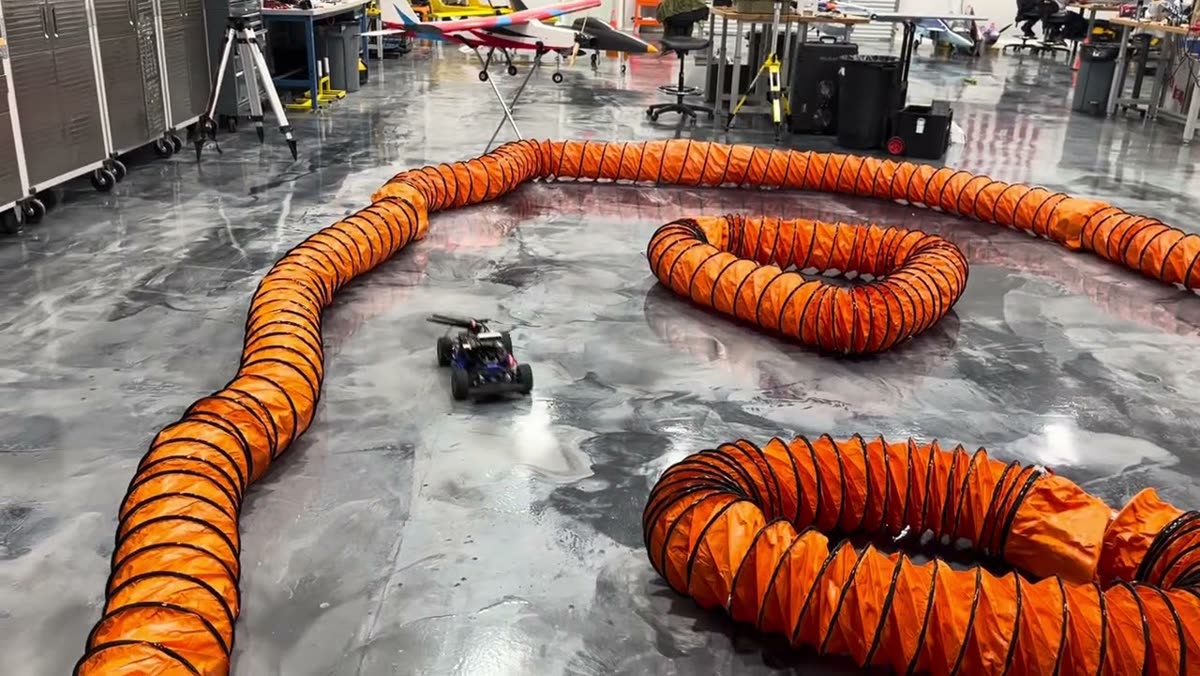
A figure eight with naive PID and the depth seeker
October 2025: the depth seeker drives a figure eight with no model, just feedback.
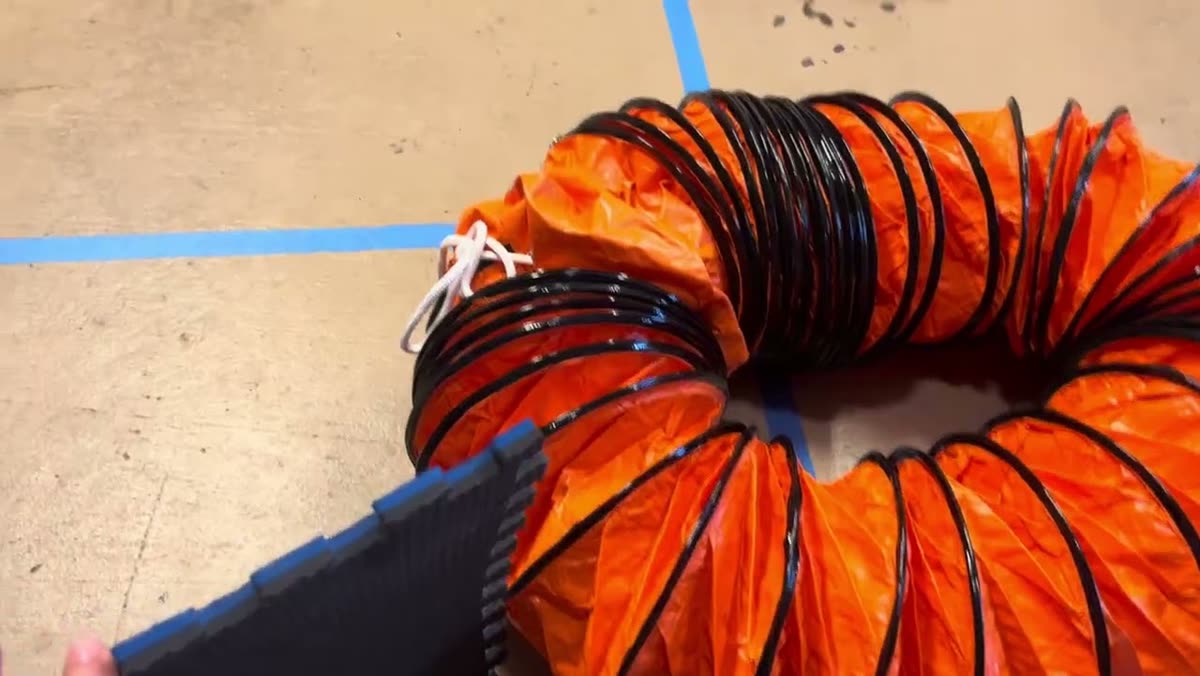
First obstacle avoidance with PID
September 2025: GOAT RACER ONE avoids obstacles with a plain PID loop and the depth camera.
GOAT CONF ONE
Our first GOAT conference, in July 2024: robots, simulation, and the community that became GOAT RACER.
Drafts
Not published yet
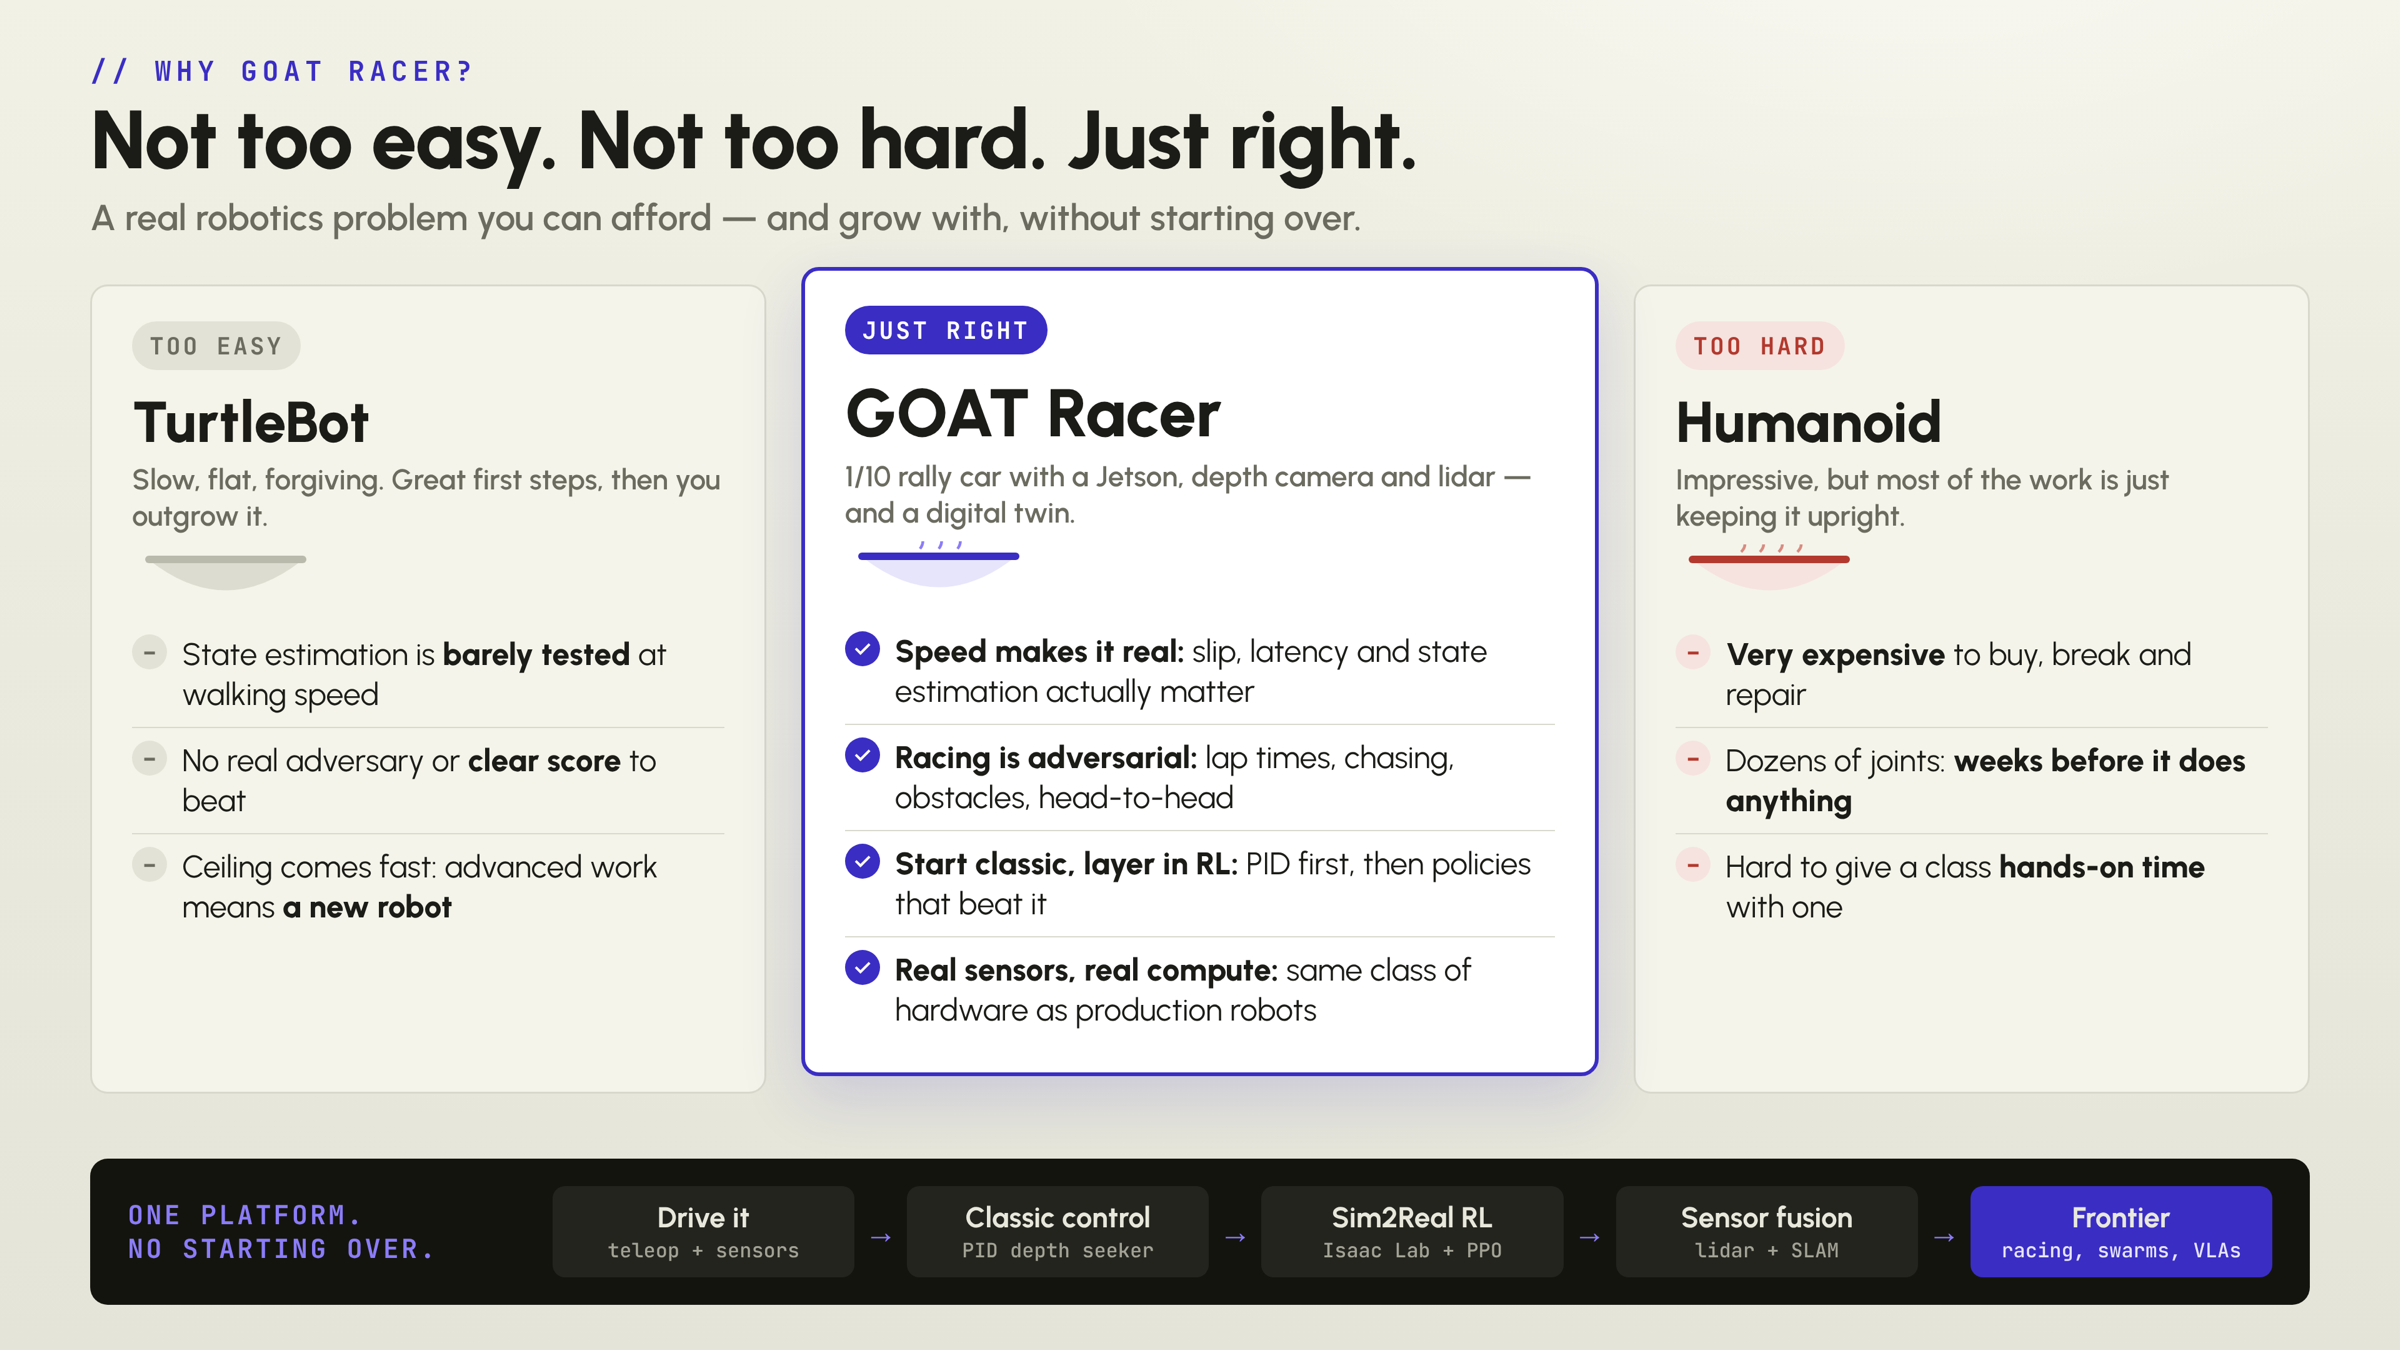
Not too easy, not too hard: why a race car
Physical AI needs a robot that is hard enough to be real and simple enough to learn on. Here is why we picked a 1/10-scale rally car.
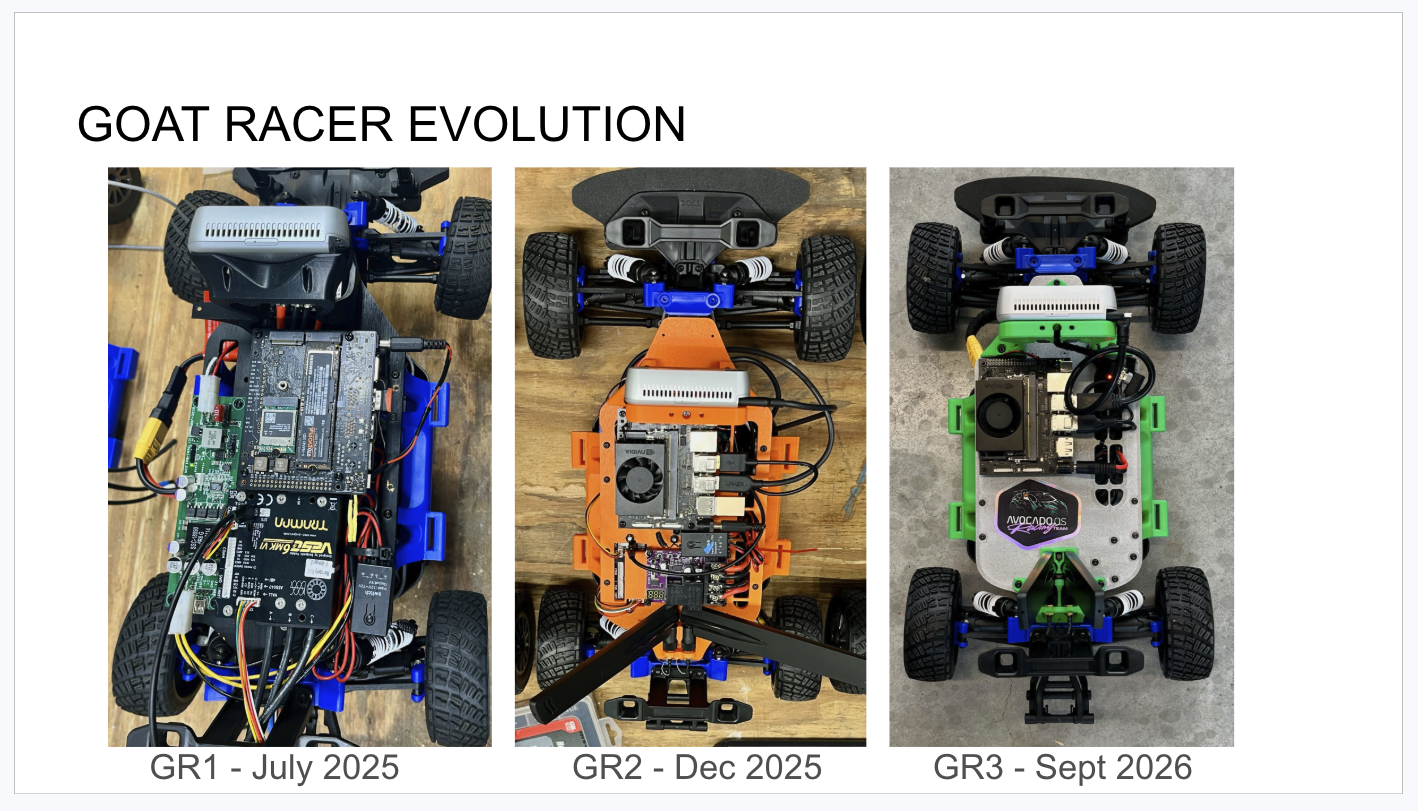
18 months to our first sim-to-real transfer
NVIDIA thought sim-to-real would be easy. It was not. What broke on the way from a simulated car to a real one, and what we learned.
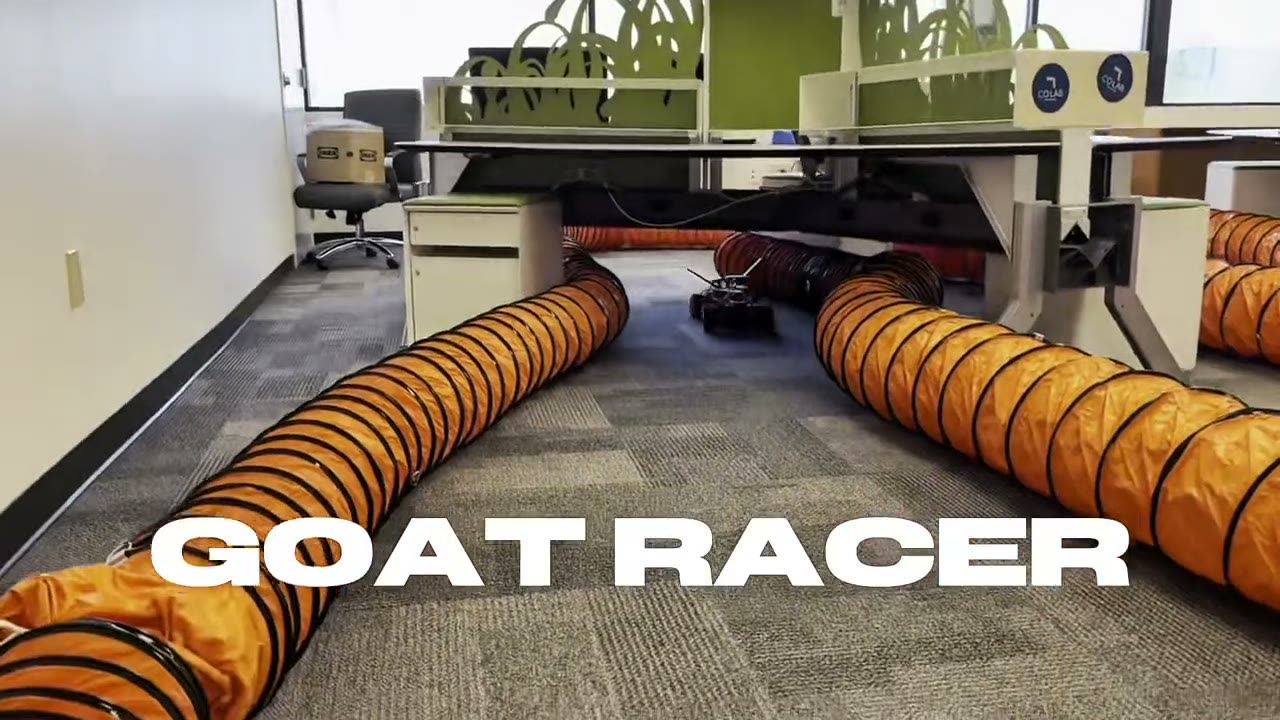
PID before RL: why we start with a depth seeker
Before any neural network touches the car, a few lines of feedback control have to drive it. Here is why every GOAT RACER student starts there.
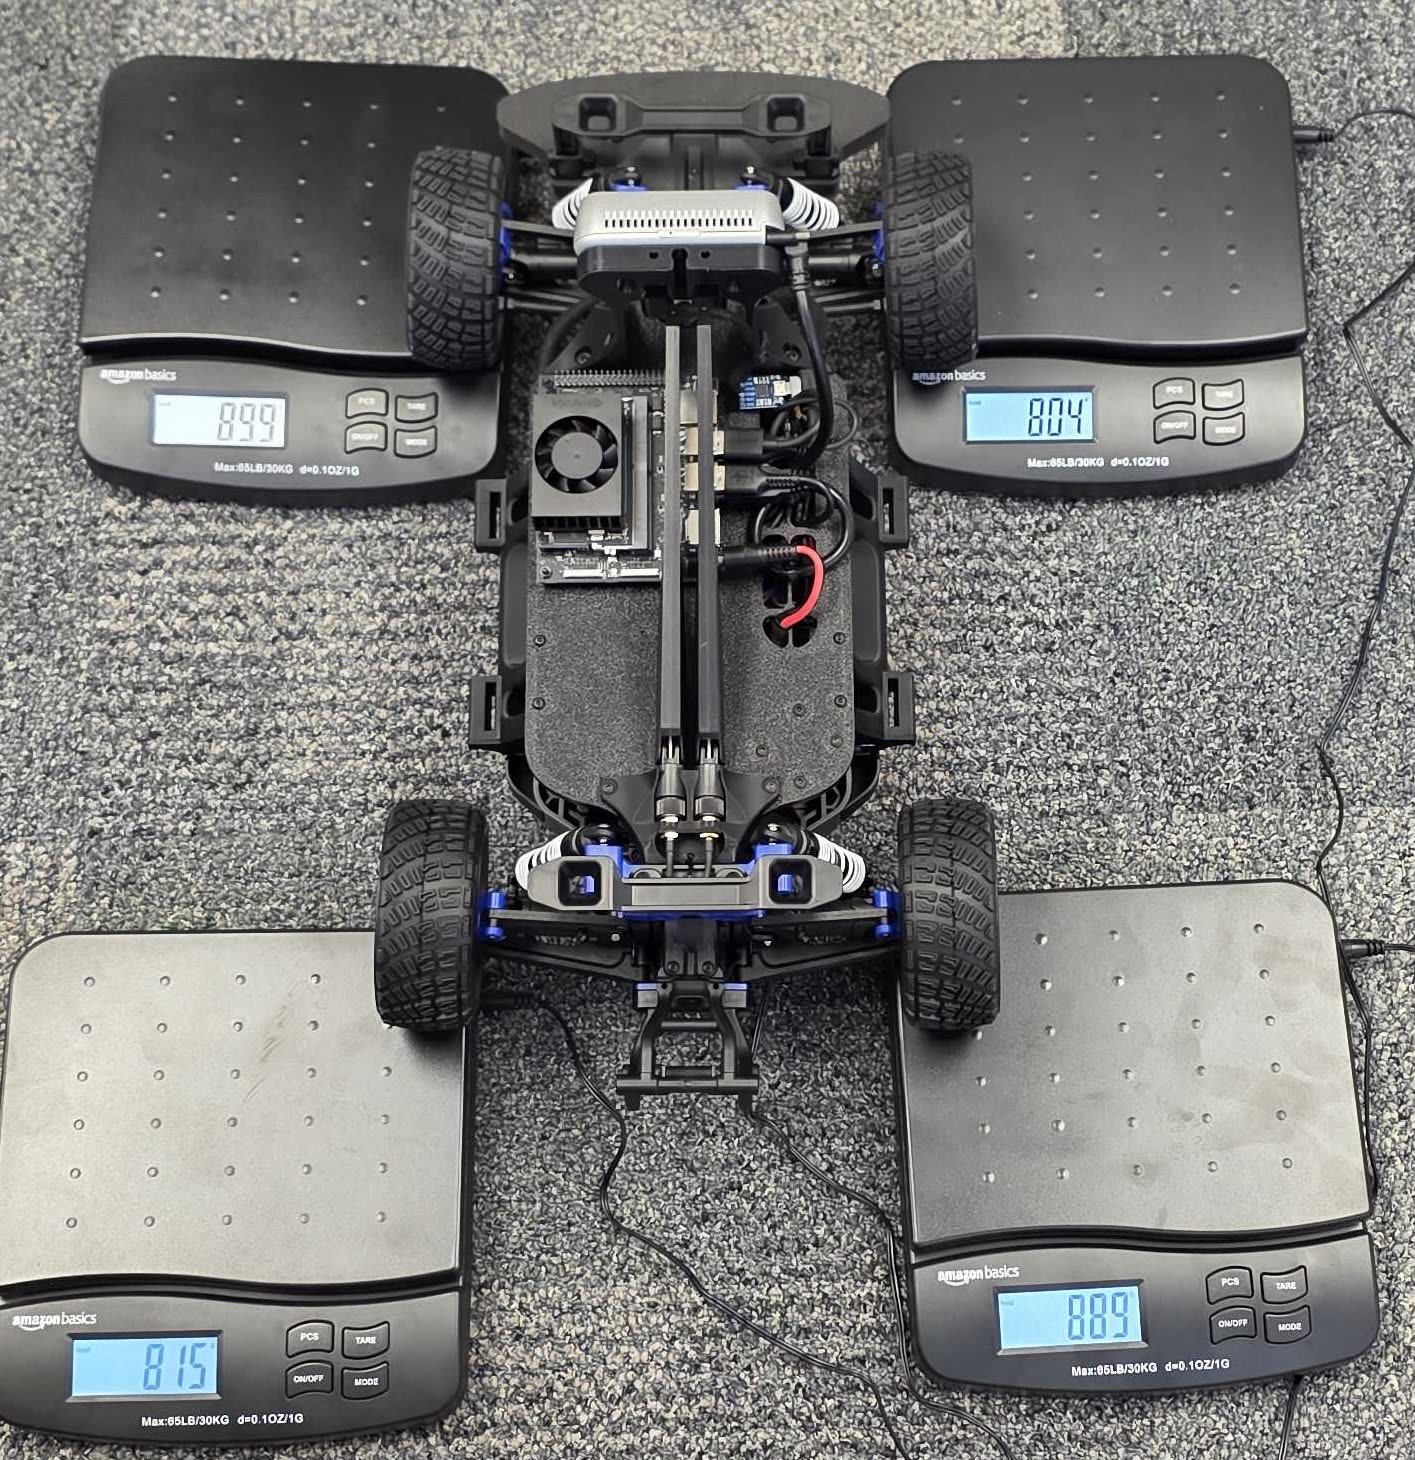
Fitting motor curves on the bench
The least glamorous work in sim-to-real may be the most valuable: measuring the real motor and putting it in the digital twin.
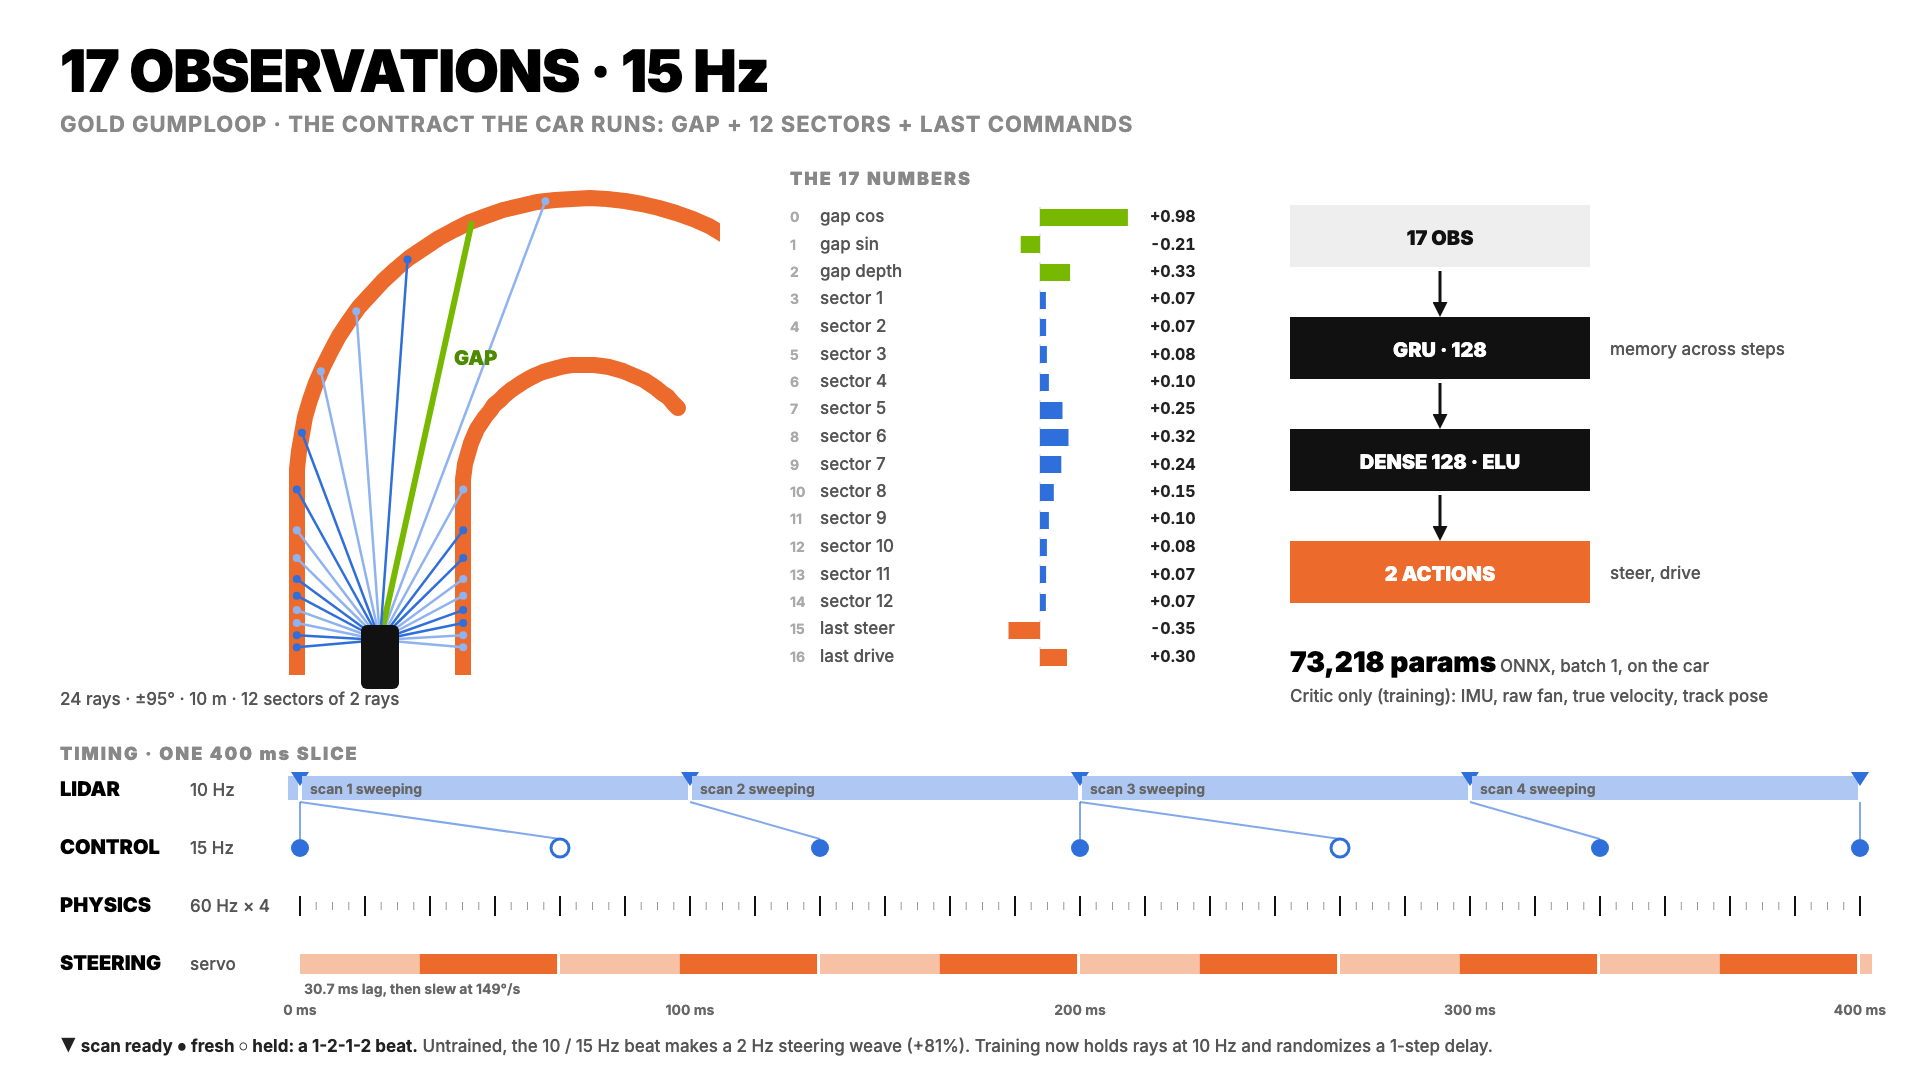
17 observations, stale lidar, and a 73,000-parameter brain
How our lidar driving policy works, and the timing bug that turned out to be one of our biggest unlocks.
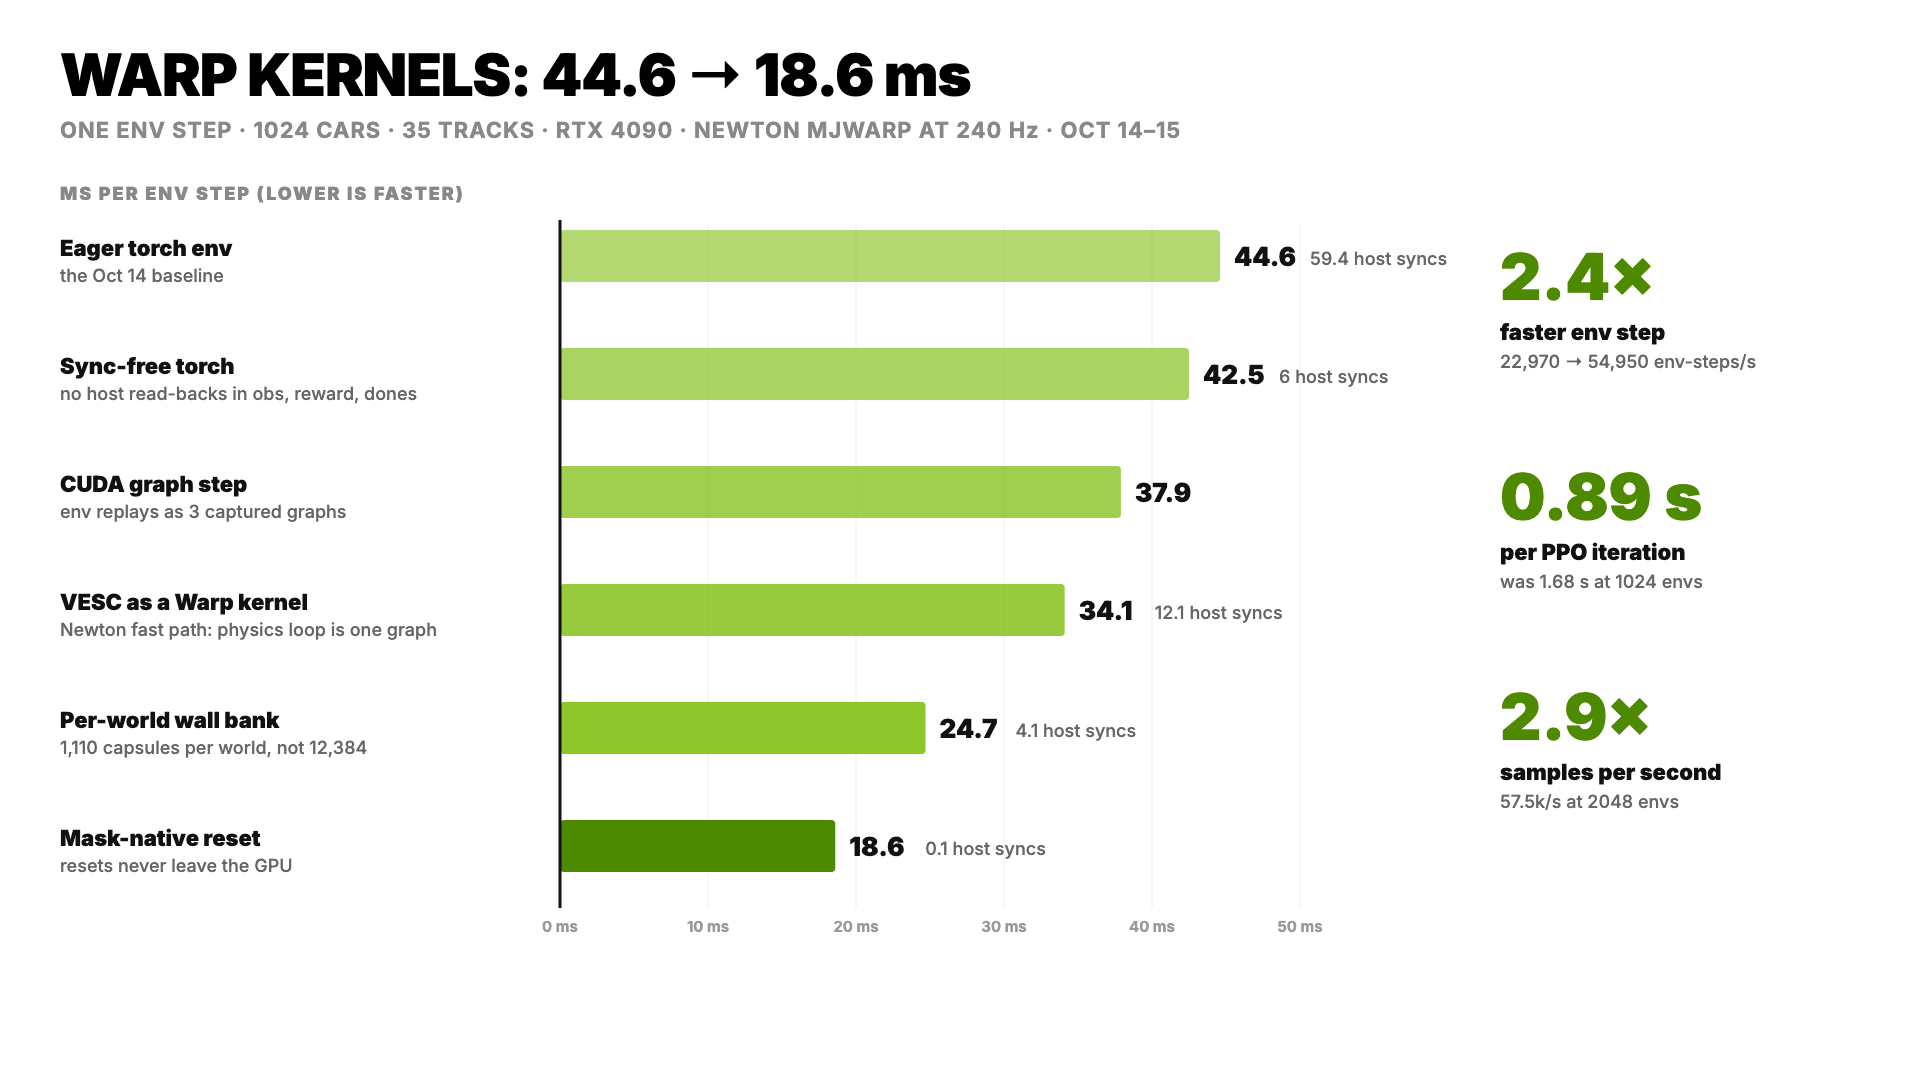
Warp kernels: 2.4× faster training on one RTX 4090
How we cut one simulation step for 1,024 cars from 44.6 ms to 18.6 ms with NVIDIA Warp and Newton.
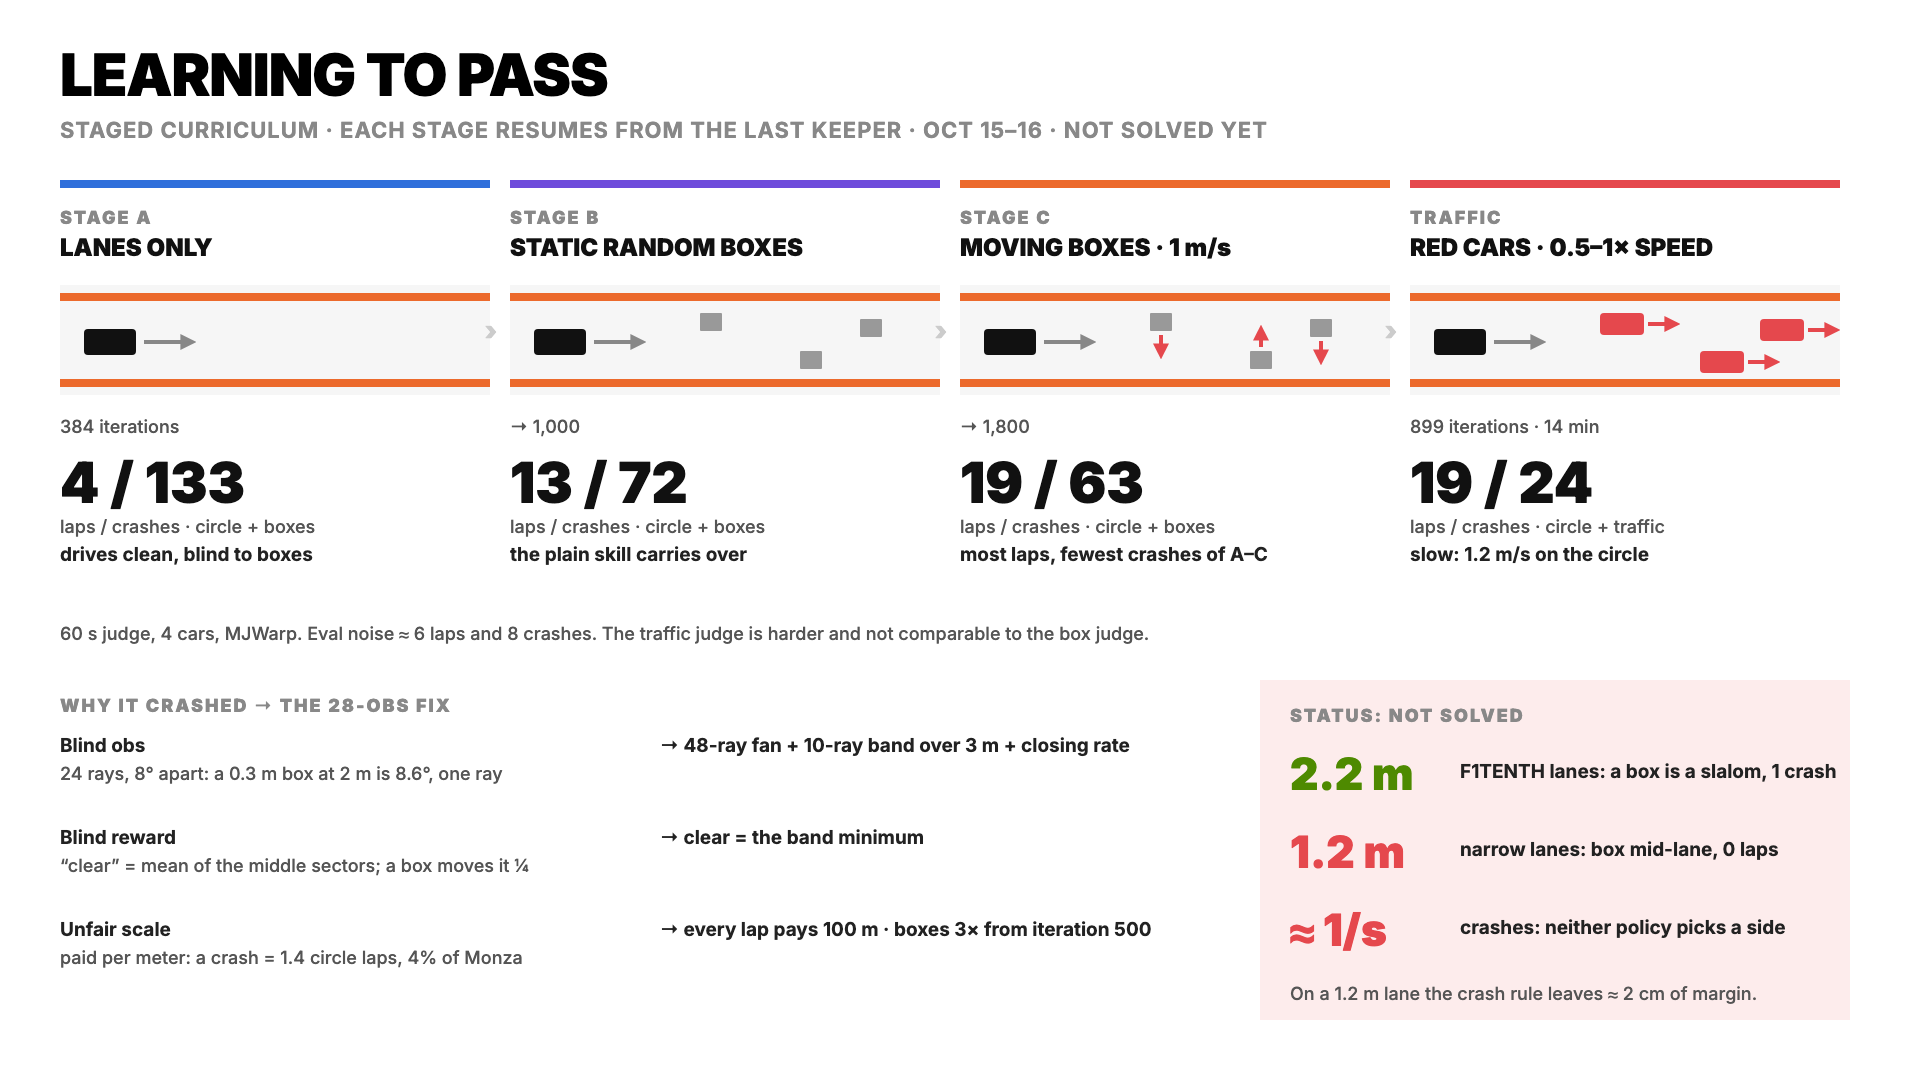
Learning to pass: an open problem
We are teaching a policy to pass obstacles and other cars with a staged curriculum. It is not solved yet. Here is where it stands.
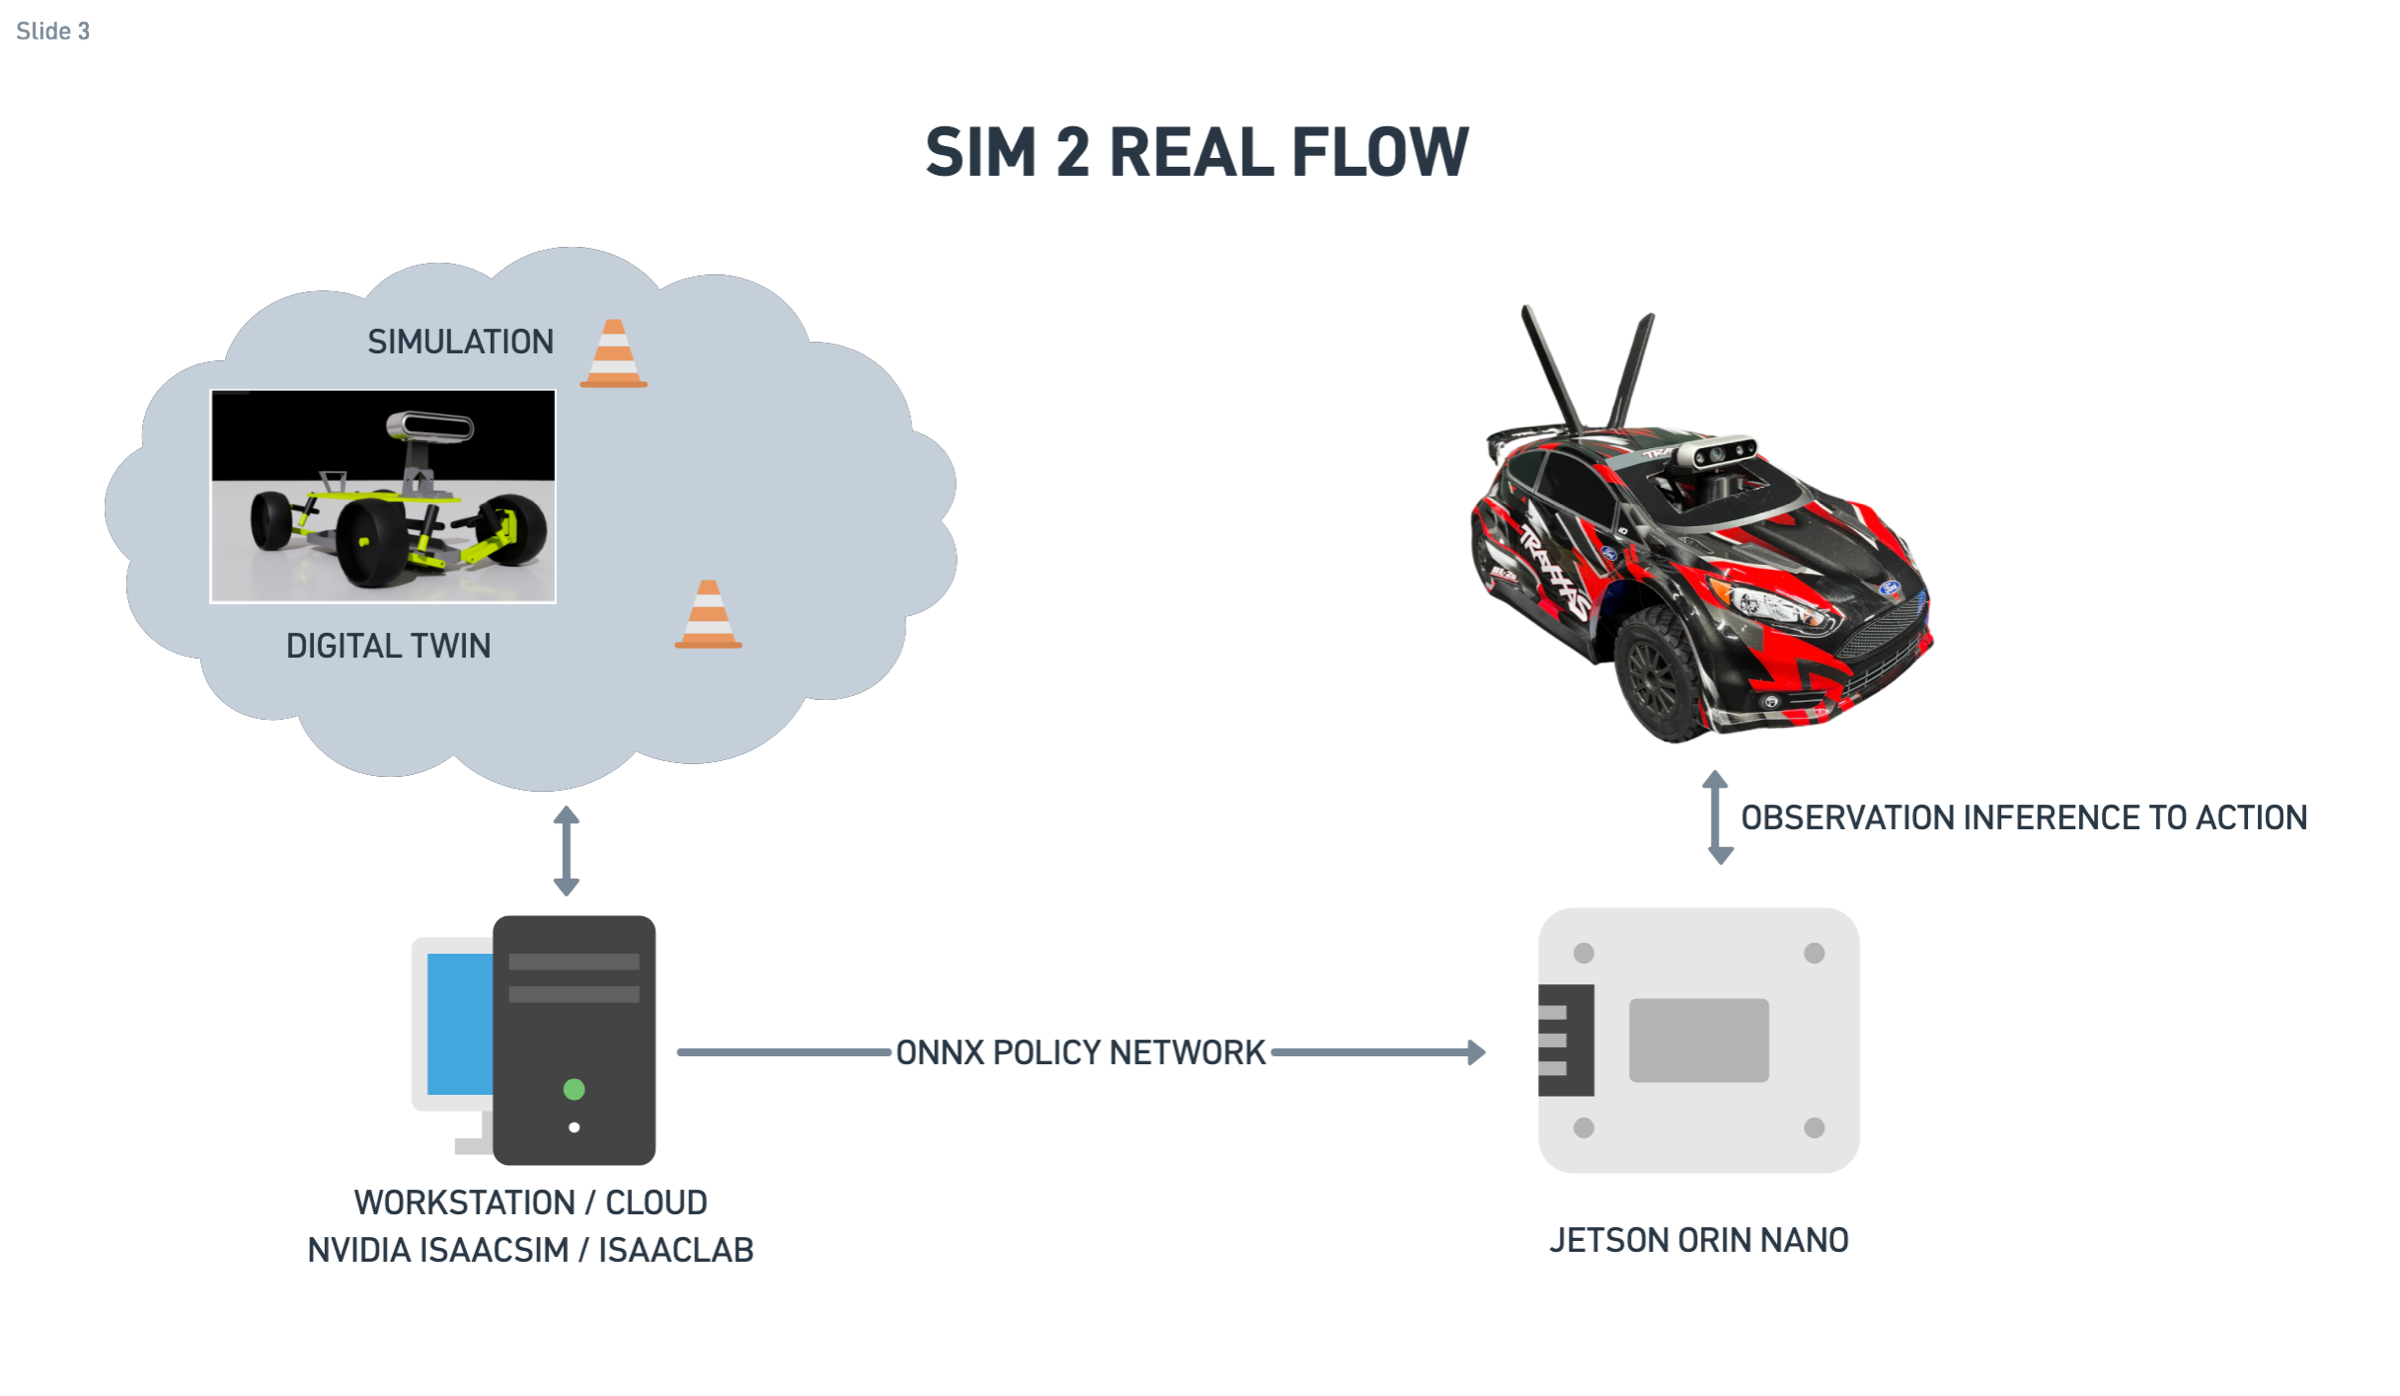
Shipping robots like software
Three cars on Docker and SDK Manager did not scale. How Avocado OS and Peridio let us update one car's policy in seconds.
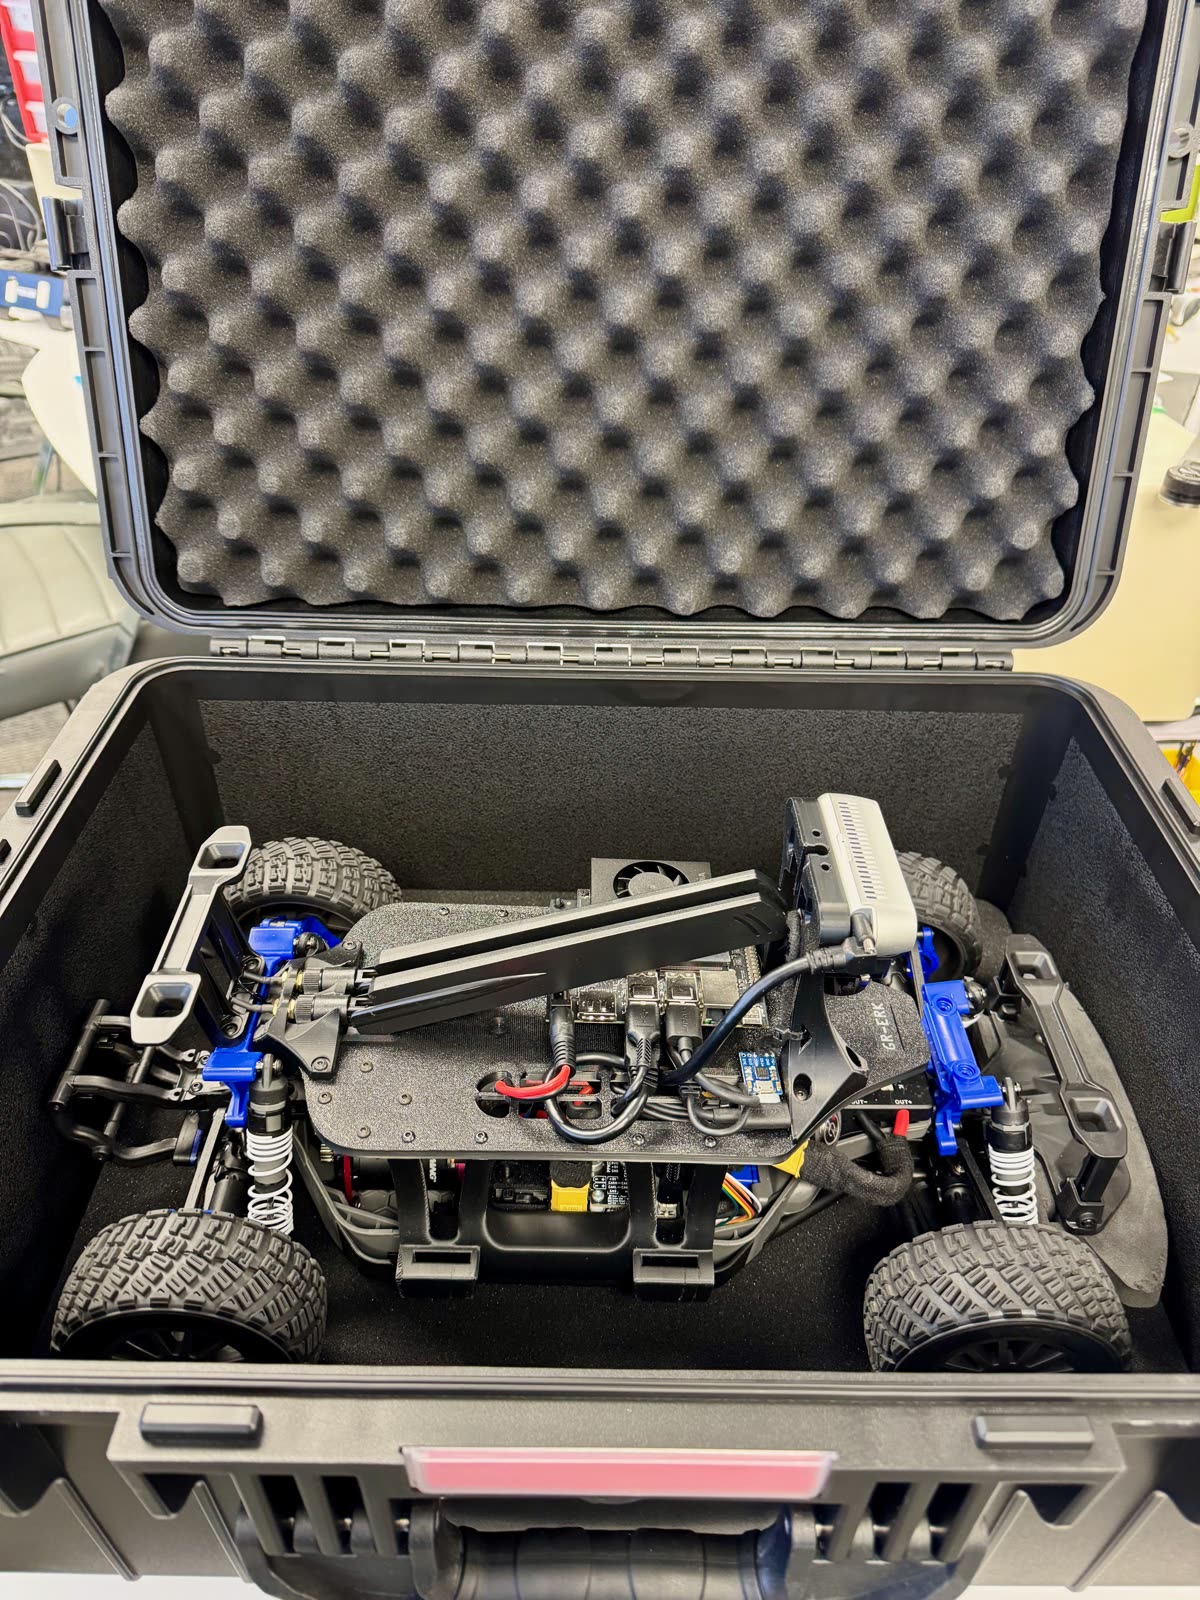
Introducing GOAT RACER and GOAT RACER PRO
Two cars, one sim-to-real loop. GOAT RACER for getting started, GOAT RACER PRO for research labs.
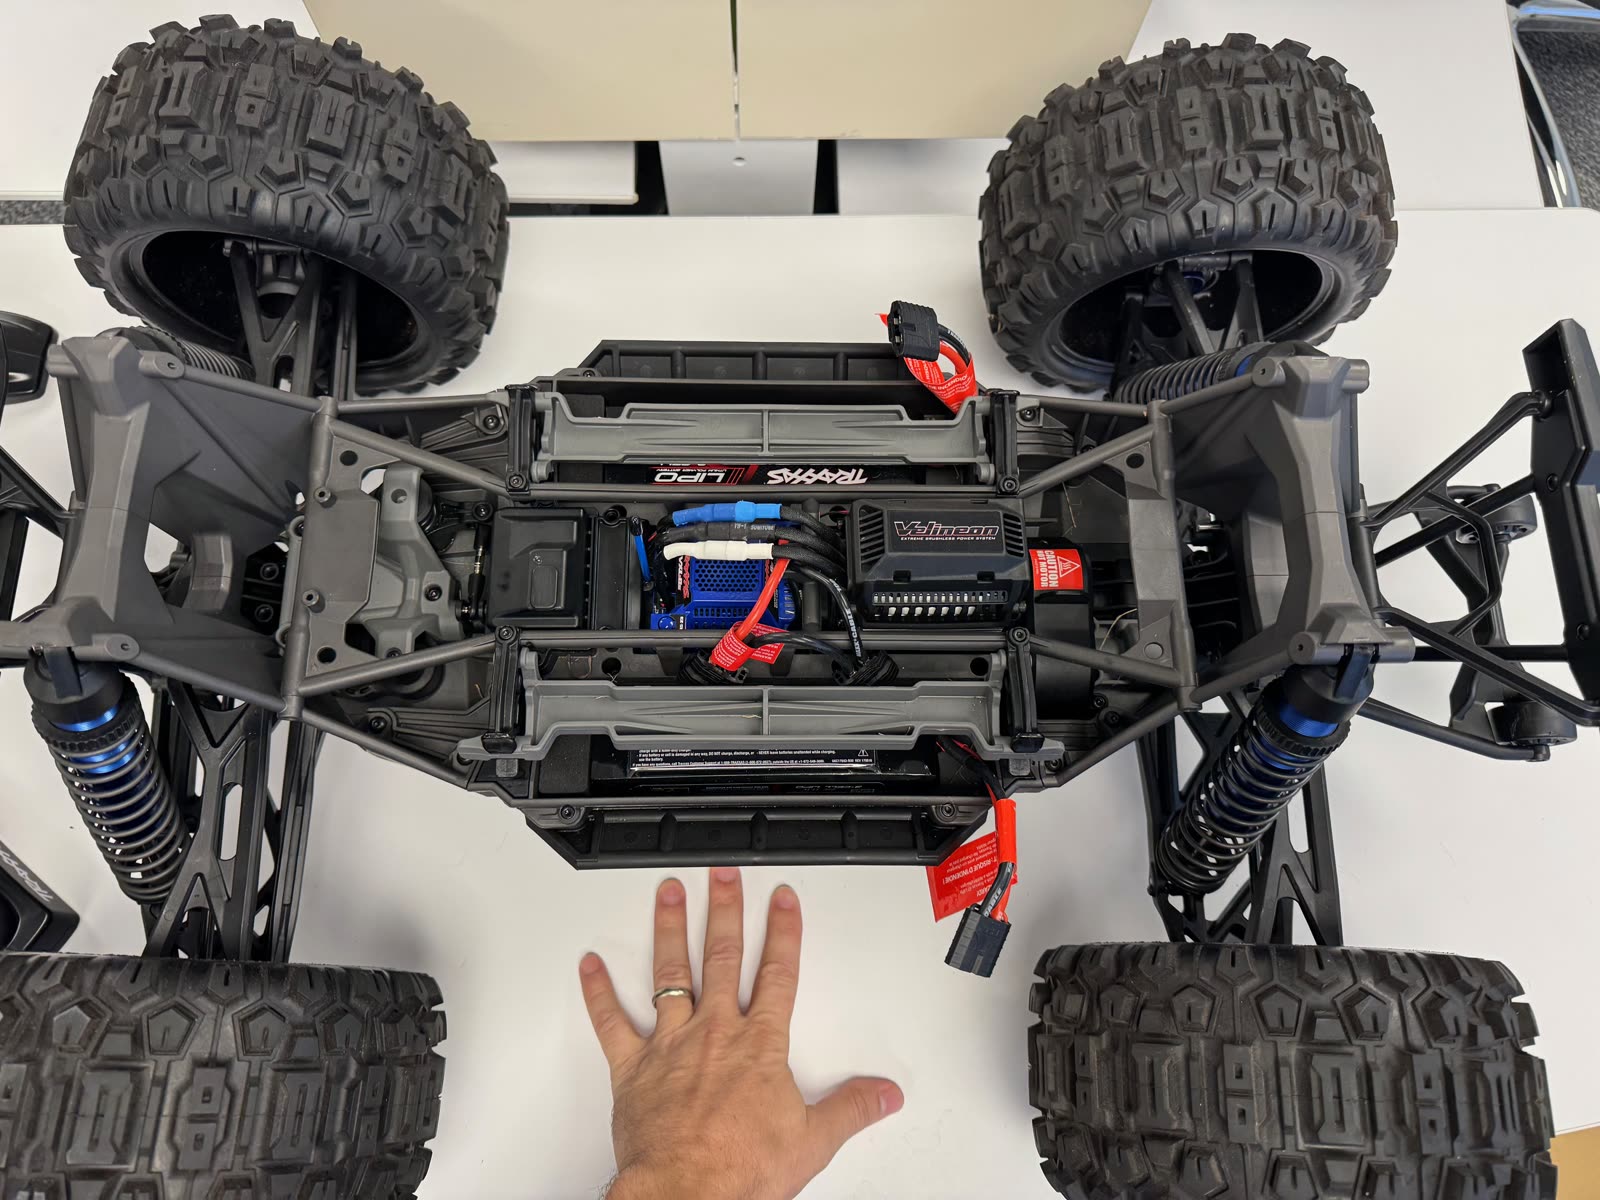
Taking it outside: 1/5 scale and solid-state lidar
Our goal was always to drive outdoors, in places without GPS. The next platform is bigger, and it sees in sunlight.