Sim to real: closing the gaps In progress
Where the digital twin and the real car disagree, how we measure each gap, and how we close it.
Research
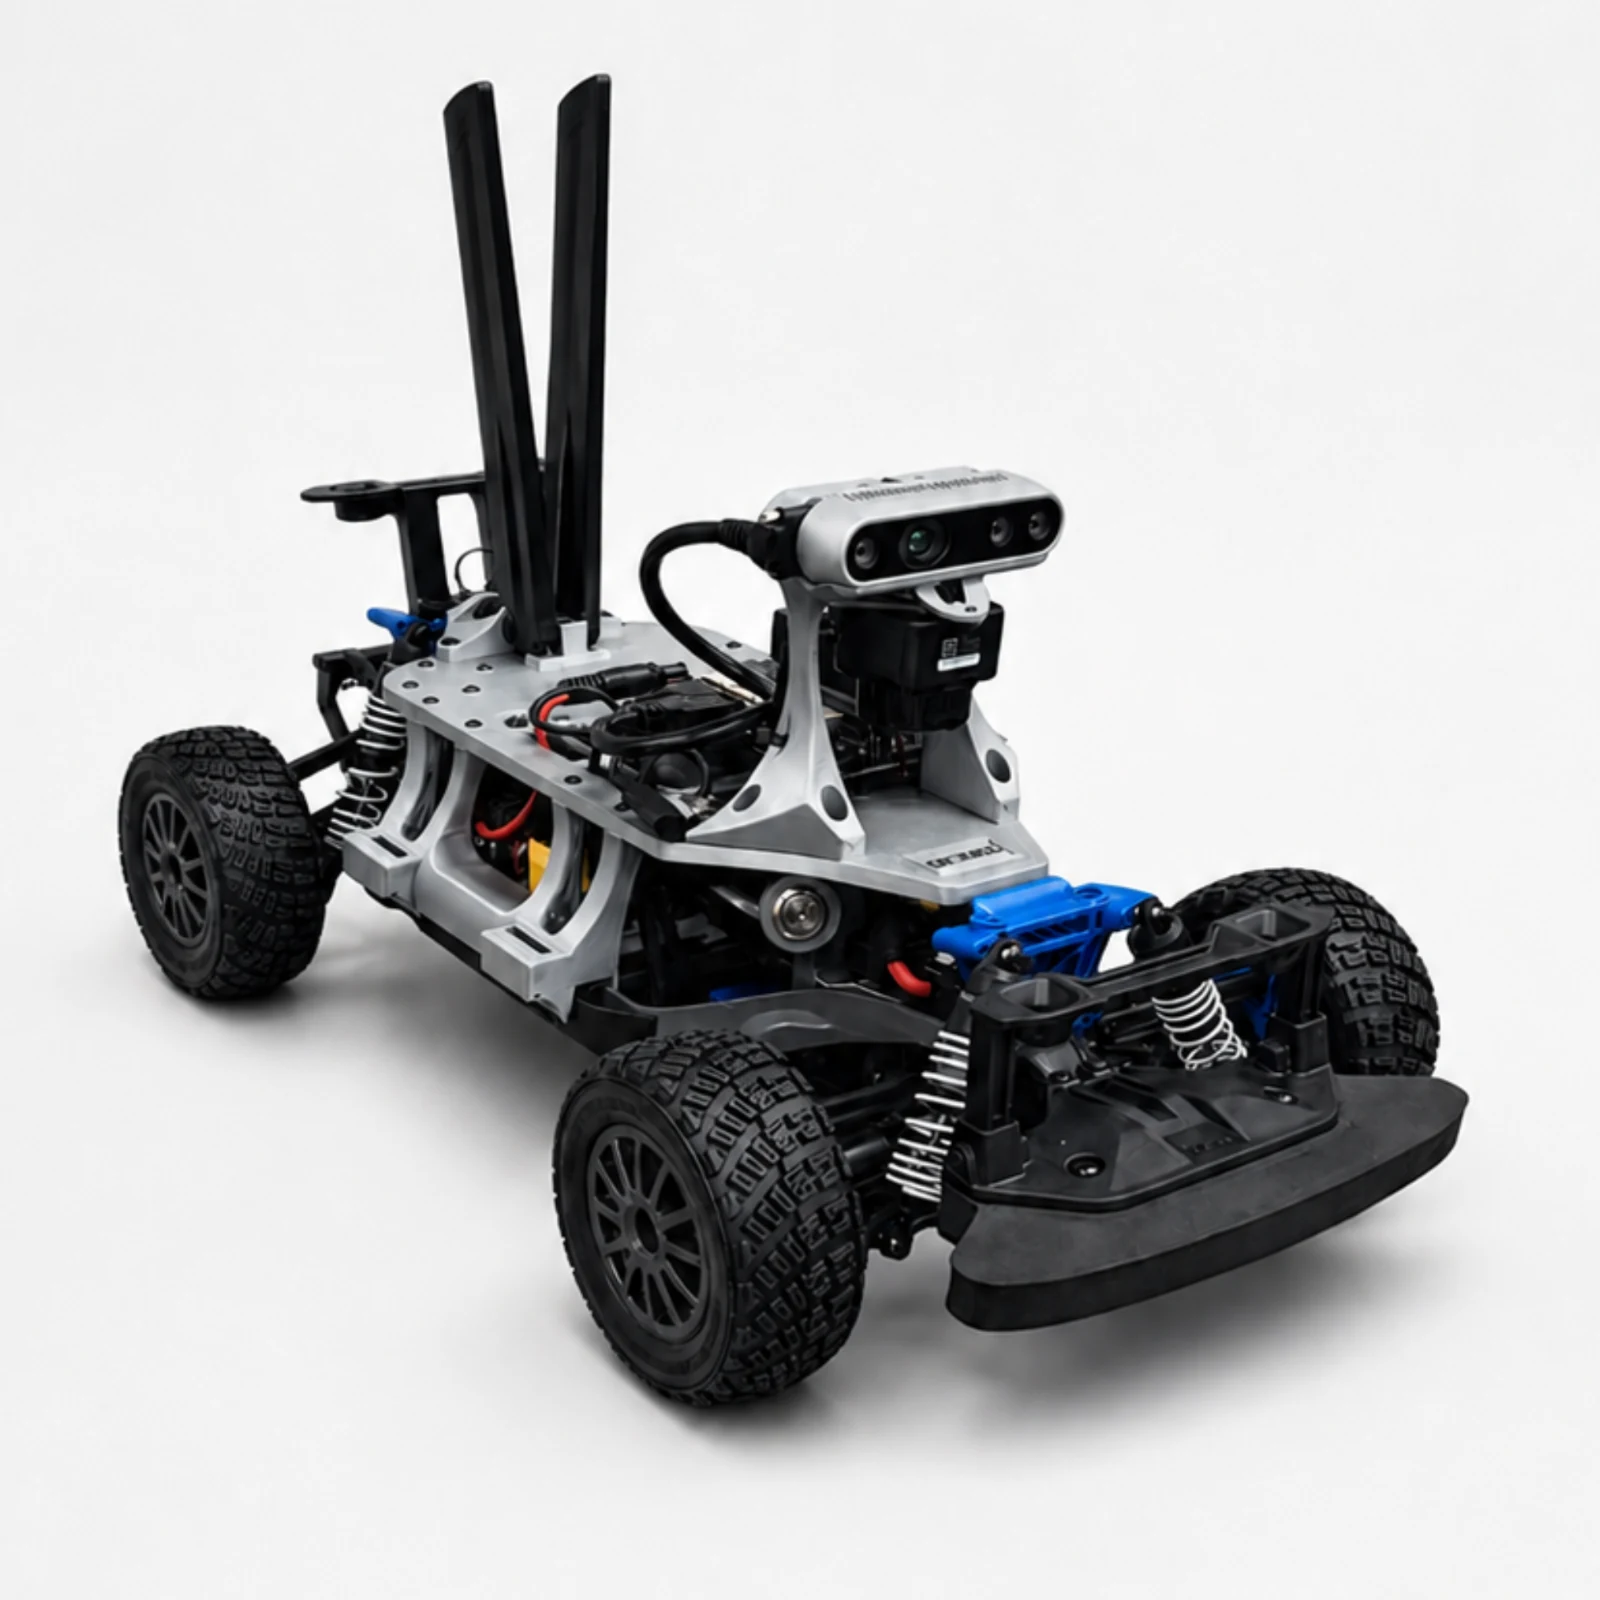
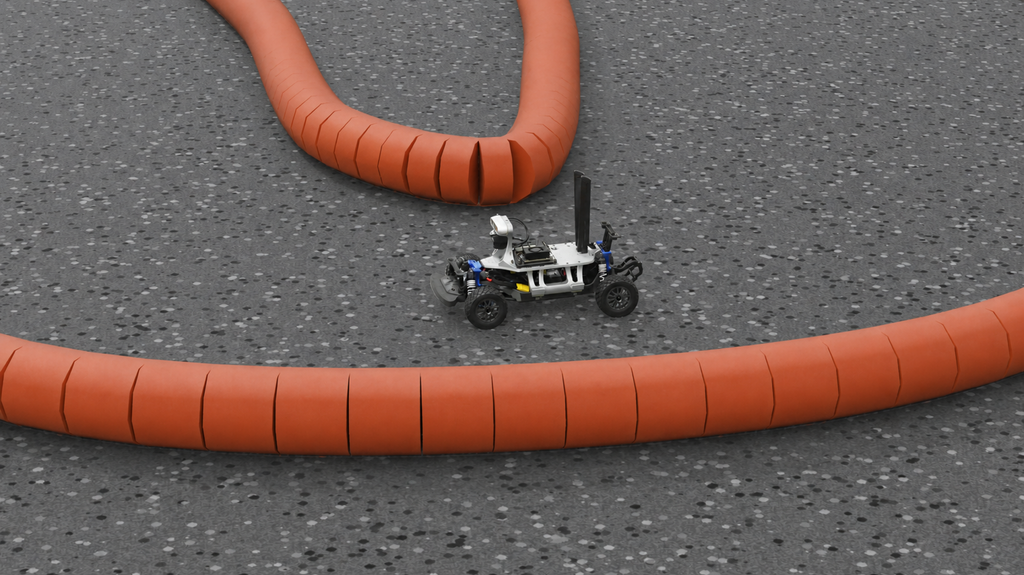
GOAT RACER is our test bed. We use it to study the gap between a trained policy and a robot in the real world.
Progress
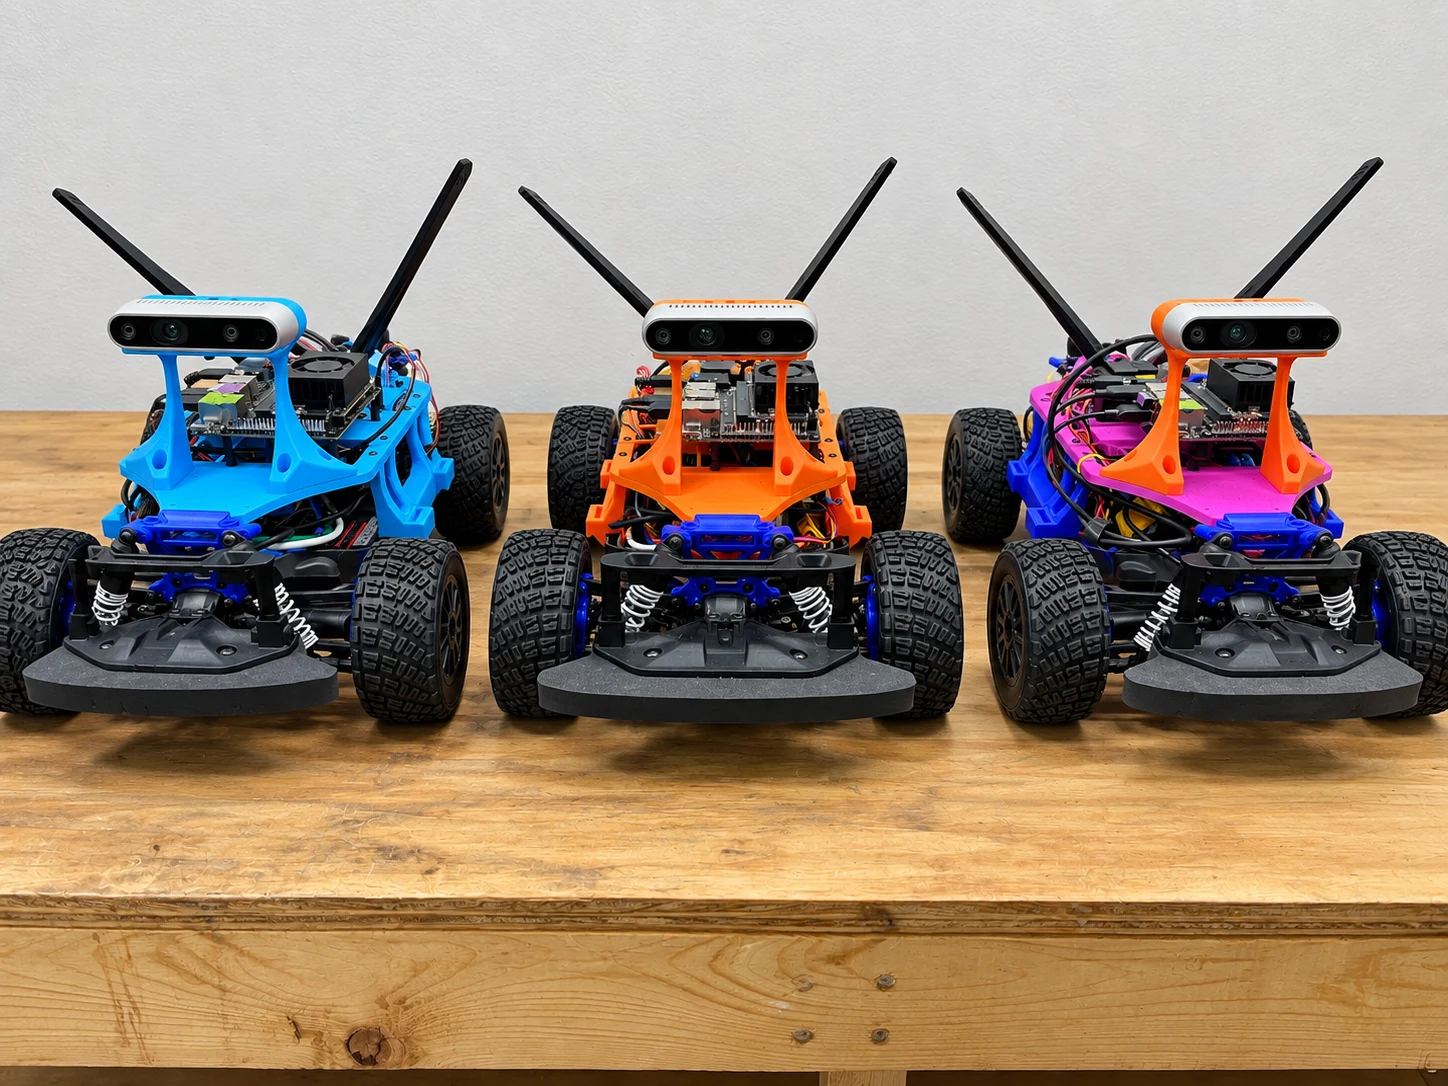
GOAT RACER started as an overnight build for a conference demo. Today, GR3 has a fixed parts list, over-the-air updates, and units in the field.
Each revision made the system easier to repeat. GR3 adds clean low-speed control, a tested digital twin, and one-click policy deployment. The same hardware and software now support research, courses, and workshops.
Robot testing, digital twins, policy transfer, mapping, swarm policies, and support for other types of robots.
Field notes
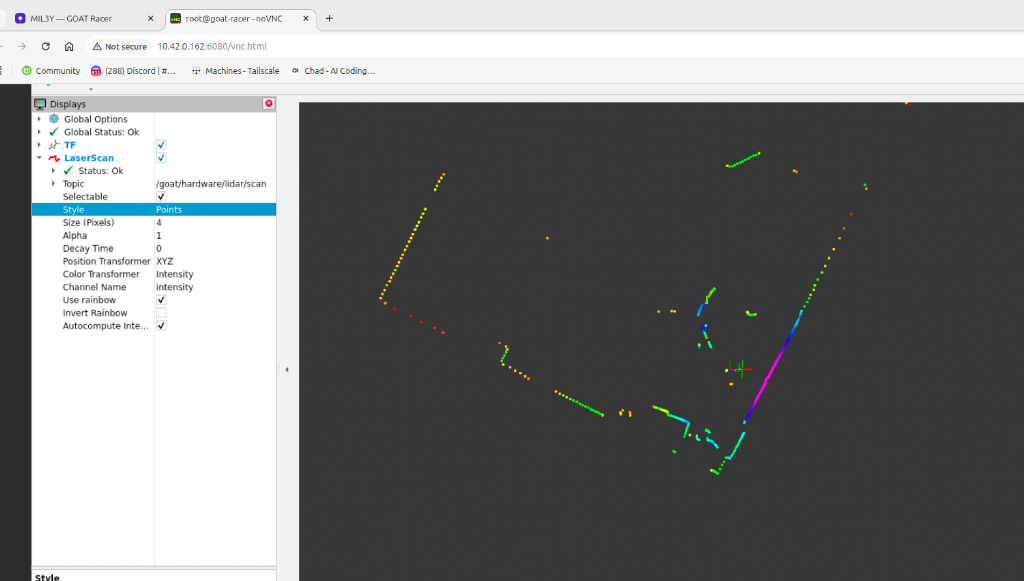
Where the digital twin and the real car disagree, how we measure each gap, and how we close it.
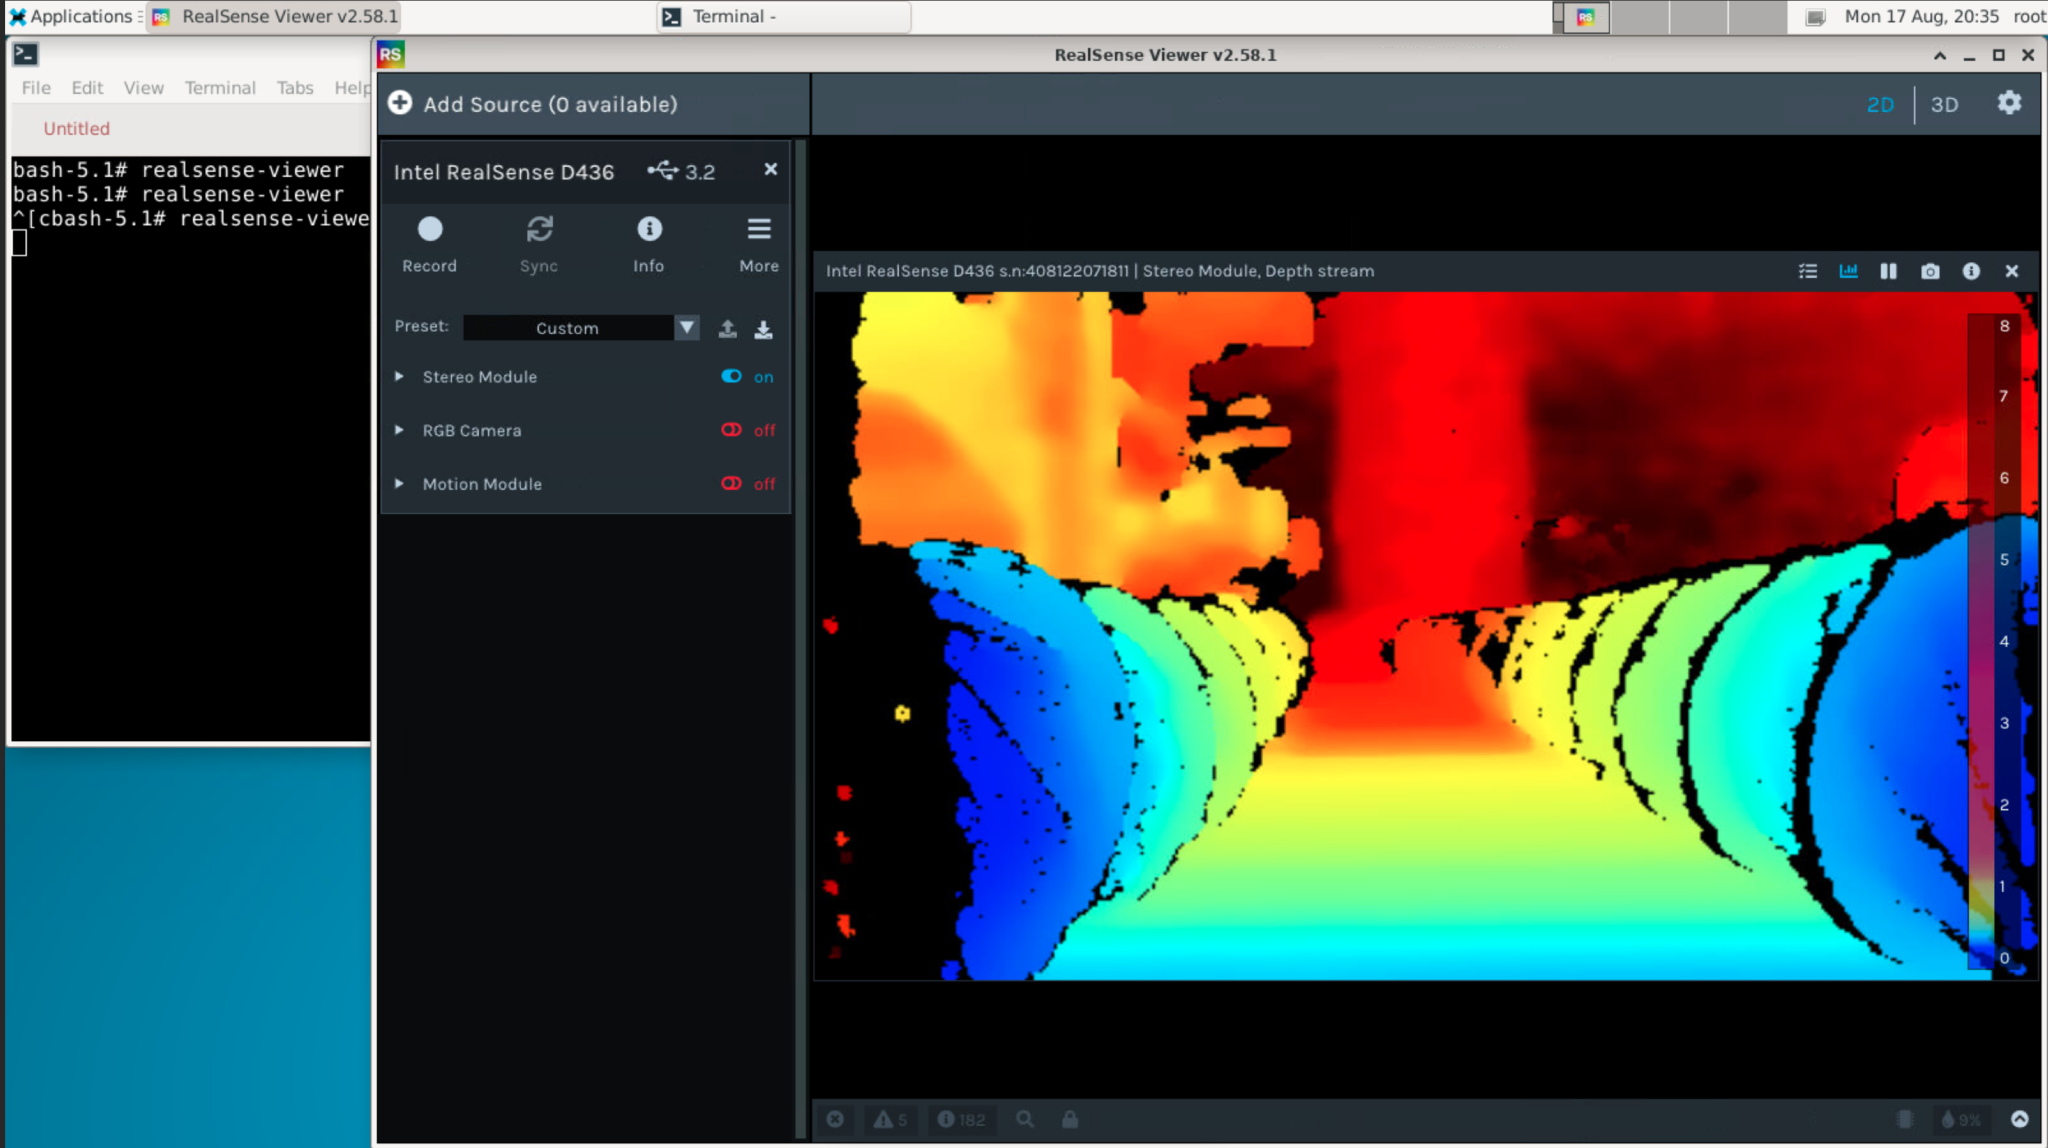
We built a ROS 2 Humble extension with Peridio's Avocado OS, packaged it as an RPM, and run it on GOAT RACER's Jetson Orin Nano.
Why a car
Steer. Throttle. Brake. The whole action space fits in your head on day one. That leaves more time for the sim-to-real loop.
A car is also cheap to crash, easy to fix, and simple to understand. The same workflow can move to other robots.